prettyprint

2022年12月7日 星期三

[Raspberry Pi Pico (c-sdk)] Display: Ep 1. PIO LCD1602A C-Code Driver & 4x4 keypad

本實驗依據 LCD1602A datasheet 撰寫以Raspberry Pi Pico PIO為基底的 C Driver。


實驗項目:

  1. 輸入啟用密碼後,控制伺服馬達轉動。
  2. 更改密碼,存在開發板上的Flash Memory。
  3. 展示LCD1602 CGRAM,Cursor Blink,Text Scroll 功能。

接線:


LCD1602指令表:

使用4 bit模式,因此每個指令須依序送出4 High bit與 4 Low bits。

例如Display clear指令為0000000001(RS,RW D7~D0),則依序送出00 0000(0x00, RS,RW D7~D4)與0x00 0001(0x01)相對Pi Pico PIO指令為:


 成果影片:


程式碼:


4x4 matrix keypad請參閱:

Raspberry Pi Pico PIO(Programmable IO) Episode 1: 4x4 matrix keypad

  • lcd1602_4b.c

#include "stdio.h"
#include "stdlib.h"
#include "pico/stdlib.h"
#include "hardware/pio.h"
#include "lcd1602_pio.h"
#include "lcd1602.h"
#include "hardware/clocks.h"
#include "string.h"
PIO lcd_pio = pio0;
uint lcd_sm = 0;
uint lcd_out_base=16; //rs, rw, db7, db6, db5, db4
uint lcd_en_pin = 22; // En

static uint8_t CGRAM[8][8] = {
    {0x00,0x0a,0x1f,0x1f,0x1f,0x0e,0x04,0x00},
    {0x1f,0x15,0x00,0x00,0x00,0x11,0x1b,0x1f},
    {0x04,0x0e,0x0a,0x0a,0x0a,0x0a,0x0e,0x00},
    {0x04,0x0e,0x0a,0x0a,0x0e,0x0e,0x0e,0x00},
    {0x04,0x0e,0x0e,0x0e,0x0e,0x0e,0x0e,0x00},
    {0x07,0x05,0x07,0x00,0x00,0x00,0x00,0x00},
    {0x00,0x00,0x00,0x00,0x00,0x00,0x00,0x00},
    {0x00,0x00,0x00,0x00,0x00,0x00,0x00,0x00}
};


void lcd1602_4b_pio_init(PIO pio, uint sm, uint out_base,  uint en_pin, uint freq) {
    uint offset=0;
    pio_sm_config c;
    offset = pio_add_program(pio, &lcd1602_4b_program);
    c = lcd1602_4b_program_get_default_config(offset);
    
    for (int i=0; i < 6; i++) pio_gpio_init(pio, out_base+i);
    pio_gpio_init(pio, en_pin);

    pio_sm_set_consecutive_pindirs(pio, sm, out_base, 6, true);
    pio_sm_set_consecutive_pindirs(pio, sm, en_pin, 1, true);

    sm_config_set_out_pins(&c, out_base, 6);
    sm_config_set_set_pins(&c, en_pin, 1);
   
    sm_config_set_jmp_pin(&c, out_base+3);
    
    sm_config_set_out_shift(&c, true, false, 32);

    float div = clock_get_hz(clk_sys)/freq;
    sm_config_set_clkdiv(&c, div);
    pio_sm_init(pio, sm, offset, &c);
    pio_sm_set_enabled(pio, sm, true);
   
}

void lcd1602_set_cursor(uint8_t line, uint8_t pos) {
    if (line > 1 || line < 0 || pos < 0 || pos > 15) return;
    pio_sm_put_blocking(pio0, 0, 0x08 | line << 2);
    pio_sm_put_blocking(pio0, 0, 0x00 | pos);
}
void lcd1602_display_cursor_on_off(uint8_t on_off, uint8_t cursor_on_off, uint8_t cursor_blink) {
    uint8_t stat = 0x8;
    if (on_off) stat = stat | (on_off << 2);
    if (cursor_on_off) {
        stat = stat | (cursor_on_off << 1);
        if (cursor_blink) stat = stat | (cursor_blink &0x01);
    }
    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x00);
    pio_sm_put_blocking(lcd_pio, lcd_sm, stat);

    
}
void lcd1602_cursor_shift(uint8_t right) {
    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x01); // cursor shift left
    if (right)
        pio_sm_put_blocking(lcd_pio, lcd_sm, 0x06);
     else 
        pio_sm_put_blocking(lcd_pio, lcd_sm, 0x04);
    
}
void lcd1602_clear() {
    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x00); //display clear
    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x01);
    sleep_ms(2);
    
}

void lcd1602_print_ch(uint8_t l, uint8_t p, uint8_t c) {
    if (l > 1 || l < 0 || p < 0 || p > 15) return;
    pio_sm_put_blocking(pio0, 0, 0x08 | l << 2);
    pio_sm_put_blocking(pio0, 0, 0x00 | p);
    pio_sm_put_blocking(pio0, 0, 0x20 | (c & 0xff) >> 4);
    pio_sm_put_blocking(pio0, 0, 0x20 | (c & 0x0f));
}
void lcd1602_print(uint8_t l, uint8_t p, uint8_t * buff) {
    if (l > 1 || l < 0 || p < 0 || p > 15) return;
    uint slen= strlen(buff);
 
    if (!slen) return;
    slen = (slen+p)>16?16-p:slen;   // max positon is 15

    for (uint8_t i = p;  i < p + slen; i++) {
        /* set address*/
        pio_sm_put_blocking(lcd_pio, lcd_sm, 0x08 | l << 2);
        pio_sm_put_blocking(lcd_pio, lcd_sm, 0x00 | i);
        /* put data */
        pio_sm_put_blocking(lcd_pio, lcd_sm, ((buff[i-p] & 0xff) >> 4) | 0x20);
        pio_sm_put_blocking(lcd_pio, lcd_sm, (buff[i-p]&0x0f) | 0x20);

    }
    
}
void lcd1602_scroll(uint8_t line, uint8_t *buff, bool left, uint16_t delay_ms, int loop_count) {
    uint8_t shift_out_char;
    uint8_t len = strlen(buff);
    uint8_t *l_buff = (uint8_t*) malloc(len+1);
    strcpy(l_buff, buff);
    lcd1602_print(line, 0, l_buff);
    for (int l = 0; l < loop_count; l++) {
        if (left) {
            sleep_ms(delay_ms);
            shift_out_char = l_buff[0];
            for (int i = 0; i < len-1; i++) {
                l_buff[i] = l_buff[i+1];
            }
            l_buff[len-1]=shift_out_char;

            lcd1602_print(line, 0, l_buff);
        

        } else {

            sleep_ms(delay_ms);
            shift_out_char = l_buff[len-1];
            for (int i = len-1; i > 0; i--) l_buff[i] = l_buff[i-1];
            l_buff[0]=shift_out_char;
            lcd1602_print(line, 0, l_buff);

        }
    }
    free(l_buff);

}
void lcd1602_pw_on_init() {
    sleep_ms(16);
    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x03);
     pio_sm_put_blocking(lcd_pio, lcd_sm, 0x03);
 
    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x03 );
    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x02);

    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x02 );  // 2 line, font 5*8 
    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x08);

    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x00);  // display on, cursor off
    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x0c);

    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x00);  // entry mode
    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x06);
  

    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x00);
    pio_sm_put_blocking(lcd_pio, lcd_sm, 0x01 );  // display clear
    sleep_ms(1000);
}
void lcd1602_write_to_CGRAM() {
    for (uint8_t i = 0; i < 8; i++) {
        pio_sm_put_blocking(lcd_pio, lcd_sm, 0x04 | ((i << 3) & 0xf0) >> 4 ); //CGRAM address i
        pio_sm_put_blocking(lcd_pio, lcd_sm, 0x00 | (i << 3)&0x0f);
        for (uint8_t j =0; j < 8; j++) {
            pio_sm_put_blocking(lcd_pio, lcd_sm, 0x20 | (CGRAM[i][j] & 0xff)>>4); //CGRAM data j
            pio_sm_put_blocking(lcd_pio, lcd_sm, 0x20 |  CGRAM[i][j] & 0x0f);
        }
    }
    
    
}
void lcd1602_init() {
    /* bits */
    lcd1602_4b_pio_init(lcd_pio, lcd_sm, lcd_out_base,  lcd_en_pin, 100000);
    
    lcd1602_pw_on_init();

    lcd1602_write_to_CGRAM();
    
}

  • lcd1602_4b.pio

.program lcd1602_4b
; RS,R/W, DB7,DB6, Db5, DB4   : bits order
.wrap_target
pull
check_busy:
set x, 0x10
mov pins, x
set pins, 0
set pins, 1 [2]
set pins, 0 [1]
jmp pin check_busy

set pins,0
out pins, 6 
set pins,1 [3]
set pins,0 [2]

  • lcd1602.h

#ifndef __LCD1602_H
#define __LCD1602_H

void lcd1602_init();
void lcd1602_print(uint8_t l, uint8_t p, uint8_t * buff);
void lcd1602_print_ch(uint8_t l, uint8_t p, uint8_t c);
void lcd1602_clear();
void lcd1602_display_cursor_on_off(uint8_t on_off, uint8_t cursor_on_off, uint8_t cursor_blink);
void lcd1602_cursor_shift(uint8_t right);
void lcd1602_set_cursor(uint8_t line, uint8_t pos);
void lcd1602_scroll(uint8_t line, uint8_t *buff, bool left, uint16_t delay_ms, int loop_count);

#endif

  • main.c

#include <stdio.h>
#include "pico/stdlib.h"
#include "hardware/pio.h"
#include "hardware/pwm.h"
#include "hardware/flash.h"
#include "lcd1602.h"
#include "keypad.h"
#include "string.h"

#define PWM_PIN 28
#define XIP_OFFSET (0x153600)

uint8_t test_passwd[7]="123456";
uint8_t passwd[7], apasswd[7];
uint8_t passLen=0;
uint8_t passRow=0;
int slice, pwm_ch;

enum {
    MENU=1,
    ENTER_PWD,
    VALIFIED,
    CHANGE_PWD
} State;

void setServoAngle(int ang) {
    uint16_t top_count = (uint16_t)(ang/0.09 + 1500);  // angle 0: 1.5 ms duty
    pwm_set_chan_level(slice, pwm_ch, top_count);

}
void show_menu() {
    lcd1602_clear();
    lcd1602_display_cursor_on_off(1,0,0);
    lcd1602_print(0,4, "Hellow!");
    lcd1602_print(1,0, "*:Enter Password");
    State = MENU;
}
void function_A() {
    setServoAngle(90);
}
void function_B() {
    setServoAngle(0);

}
void save_password() {
    char tempbuff[256];
    lcd1602_clear();
    lcd1602_display_cursor_on_off(1,0,0);
    lcd1602_print(0,0, "PWD Changed!");
    strcpy(test_passwd,passwd);
    memset(tempbuff, 0, 256);
    sprintf(tempbuff, "Password:%s", passwd);
    flash_range_erase(XIP_OFFSET, 4096);
    flash_range_program(XIP_OFFSET, tempbuff, 256);
    sleep_ms(1000);
    show_menu();
}
void load_password() {
    char tempbuff[256];
    memset(tempbuff, 0, 256);
    strncpy(tempbuff, (uint8_t*)(XIP_BASE+XIP_OFFSET), 15);
    if (strstr(tempbuff, "Password:")) {
        memset(test_passwd, 0, 6);
        for (int i =0; i < 6; i++) {
            test_passwd[i]=*(uint8_t*)(XIP_BASE+XIP_OFFSET+9+i);
        }
    }
}
void servo_init() {
    // set Servo pwm
    gpio_set_function(PWM_PIN, GPIO_FUNC_PWM);
    slice = pwm_gpio_to_slice_num(PWM_PIN);
    pwm_ch = pwm_gpio_to_channel(PWM_PIN);
    pwm_config c = pwm_get_default_config();
    pwm_config_set_clkdiv(&c, 125);  // 20ms period, steps 20000, clkdiv = 125 
    pwm_config_set_wrap(&c, 20000);
    pwm_config_set_phase_correct(&c, false);
    pwm_init(slice, &c, true);    
    
    setServoAngle(0);
}
void show_change_pwd() {
    lcd1602_clear();
    lcd1602_display_cursor_on_off(1,1,1);
    lcd1602_print(0,0, "Enter PWD:");
    lcd1602_print(1,0, "PWD AGAIN:");
    passRow=0;
    lcd1602_set_cursor(passRow,10);
    memset(passwd,0,6);
    memset(apasswd,0,6);
    passLen=0;
    State=CHANGE_PWD;
}

void demo() {
    lcd1602_clear();
    lcd1602_print(0, 0, "Some Demos");
    sleep_ms(1000);
    lcd1602_print(0, 0, "Print CGRAM Char");
    lcd1602_print_ch(1,0,0);
    lcd1602_print_ch(1,1,1);
    lcd1602_print_ch(1,2,2);
    lcd1602_print_ch(1,3,3);
    lcd1602_print_ch(1,4,4);
    lcd1602_print_ch(1,5,5);
    sleep_ms(3000);
    lcd1602_clear();
    lcd1602_print(0, 0, "Cursor On     ");
    lcd1602_display_cursor_on_off(1, 1, 0);
    lcd1602_print(1, 0, "              ");
    lcd1602_set_cursor(1,5);
    sleep_ms(3000);
    lcd1602_print(0, 0, "Cursor Blink   ");
    lcd1602_display_cursor_on_off(1, 1, 1);
    lcd1602_print(1, 0, "               ");
    lcd1602_set_cursor(1,5);
    sleep_ms(4000);
    lcd1602_print(0, 0, "Cursor Off    ");
    lcd1602_display_cursor_on_off(1, 0, 0);
    lcd1602_print(1, 0, "              ");
    lcd1602_set_cursor(1,5);
    sleep_ms(2000);
    lcd1602_print(0, 0, "Scroll left   ");
    lcd1602_scroll(1, "This is a scrolling messages.",true, 500, 20);
    lcd1602_clear();
     sleep_ms(1000);
    lcd1602_print(0, 0, "Scroll Right   ");
    lcd1602_scroll(1, "This is a scrolling messages.",false, 500, 20);
 
 show_menu();

}

int main()
{
    uint8_t key;
    
    stdio_init_all();
    keypad_init();
    lcd1602_init();
    load_password();
    servo_init();
    
    show_menu();
    while (1) {
        key = get_new_keypad_value();
        switch (key) {
            case 0:
            break;
            case '*':
                lcd1602_clear();
                lcd1602_display_cursor_on_off(1,1,1);
                lcd1602_print(0,0, "Enter PWD:");
                lcd1602_print(1,0, "C:Menu, #:Enter ");
                lcd1602_set_cursor(0,10);
                State=ENTER_PWD;
                memset(passwd,0,6);
                passLen=0;
                passRow=0;
            break;
            case '#':
                if (State == ENTER_PWD) {
                    if (strcmp(passwd, test_passwd)==0) {
                        State = VALIFIED;
                        lcd1602_display_cursor_on_off(1,0,0);
                        lcd1602_print(0,0, "A: UP, B:Down   ");
                        lcd1602_print(1,0, "Confirm!       ");
                        sleep_ms(1000);      
                        lcd1602_print(1,0, "C:Menu, D:CH PWD");     
                    }
                    else {
                        lcd1602_print(1,0, "Password Error! ");
                        lcd1602_print(0,10,"      ");
                        lcd1602_display_cursor_on_off(1,1,1);
                        lcd1602_set_cursor(0,10);
                        memset(passwd,0,6);
                        passLen=0;
                    }
                } 
                if (State == CHANGE_PWD) {
                    if (passRow == 0) {
                        lcd1602_set_cursor(++passRow, 10);
                        passLen=0;
                    } else {
                        if (strcmp(passwd, apasswd)!=0) {
                            lcd1602_clear();
                            lcd1602_print(1,0, "Mismatch!");
                            sleep_ms(1000); 
                            show_change_pwd();
                        } else {
                            save_password();
                        }
                    }


                }
            break;
            case 'A':
                if (State == VALIFIED) {
                    
                    function_A();
                }
            break;
            case 'B':
                if (State == VALIFIED) {
                    
                    function_B();
                }
            break;
            case 'C':
                show_menu();
                demo();

            break;
            case 'D':
                if (State == VALIFIED) {
                    show_change_pwd();
                }
            break;
            default:
                if ((State==ENTER_PWD || State == CHANGE_PWD) && passLen < 6) {
                    lcd1602_print_ch(passRow,10+passLen, '*');
                    if (passRow == 0) 
                        passwd[passLen++] = key;
                    else 
                        apasswd[passLen++] = key;
                }
            break;
        }
        sleep_ms(1);
    }
    return 0;
}


2022年12月1日 星期四

[Raspberry Pi Pico (c-sdk)] Storage: Ep 3. Using SD/MMC Devices and Flash Devices Together

 本實驗 整合SD/MMC Card與Flash Memory device一起使用。


  • 測試項目:

  1. SD/MMC Low Level Disk I/O,沒有使用檔案系統,直接進行Sector Address I/O
  2. SD/MMC 在有沒有使用DMA時,I/O效能比較。
  3. 同時掛載SD/MMC Card與Flash memory device進行I/O測試。
SD/MMC driver程式寫作參考網址 FatFs - Generic FAT Filesystem Module,Flash memory device driver程式碼請參閱上篇文章:[Raspberry Pi Pico (c-sdk)] Storage: Ep 2. Multi external flash memory devices with FatFs filesystem

  • SPI 腳位連接:
  • ffconf.h修改項目:


展示影片:


程式碼:

  • glue.c
#include "stdio.h"
#include "stdlib.h"
#include "ff.h"
#include "diskio.h"
#include "spi_sdmmc.h"
#include "W25Q.h"
#include "hardware/rtc.h"
#include "inttypes.h"

#define SDMMC_DRV_0     0
#define W25Q_DRV_1      1

sdmmc_data_t *pSDMMC=NULL;
w25q_data_t *pW25Q = NULL;

//==================//
DSTATUS disk_initialize (BYTE drv){
    DSTATUS stat;
    switch (drv) {
        case SDMMC_DRV_0:
            if (pSDMMC == NULL) {
                pSDMMC = (sdmmc_data_t*)malloc(sizeof(sdmmc_data_t));
                pSDMMC->csPin = SDMMC_PIN_CS;
                pSDMMC->spiPort = SDMMC_SPI_PORT;
                pSDMMC->spiInit=false;
                pSDMMC->sectSize=512;
#ifdef __SPI_SDMMC_DMA
                pSDMMC->dmaInit=false;
#endif
    }
            stat = sdmmc_disk_initialize(pSDMMC);
            return stat;
        break;
        case W25Q_DRV_1:
        if (pW25Q == NULL) {
            pW25Q = (w25q_data_t*)malloc(sizeof(w25q_data_t));
            pW25Q->spiInit=false;
            pW25Q->Stat=STA_NOINIT;
        }
		stat = w25q_disk_initialize(W25Q_SPI_PORT, W25Q_PIN_CS, pW25Q); 
		return stat;
		
	    break;
    }
    return STA_NOINIT;
 }
/*-----------------------------------------------------------------------*/
/* Get disk status                                                       */
/*-----------------------------------------------------------------------*/
DSTATUS disk_status (BYTE drv) {
    DSTATUS stat;
    switch (drv) {
        case SDMMC_DRV_0:
            stat=  sdmmc_disk_status(pSDMMC); /* Return disk status */
            return stat;
        break;
        case W25Q_DRV_1:
            stat = pW25Q->Stat;
            return stat;
        break;
    }
    return RES_PARERR;
	
}

/*-----------------------------------------------------------------------*/
/* Read sector(s)                                                        */
/*-----------------------------------------------------------------------*/
DRESULT disk_read (
	BYTE drv,		/* Physical drive number (0) */
	BYTE *buff,		/* Pointer to the data buffer to store read data */
	LBA_t sector,	/* Start sector number (LBA) */
	UINT count		/* Number of sectors to read (1..128) */
)
{
    DSTATUS stat;
    switch (drv) {
        case SDMMC_DRV_0:
            stat = sdmmc_disk_read(buff, sector, count, pSDMMC);
            return stat;
        break;
        case W25Q_DRV_1:
            if (pW25Q->Stat & STA_NOINIT) return RES_NOTRDY;
		    w25q_read_sector((uint32_t)sector, 0, buff, count*pW25Q->sectorSize, pW25Q);
            return pW25Q->Stat;
        break;
    }
	return RES_PARERR;
}

/*-----------------------------------------------------------------------*/
/* Write sector(s)                                                       */
/*-----------------------------------------------------------------------*/
#if FF_FS_READONLY == 0
DRESULT disk_write (
	BYTE drv,			/* Physical drive number (0) */
	const BYTE *buff,	/* Ponter to the data to write */
	LBA_t sector,		/* Start sector number (LBA) */
	UINT count			/* Number of sectors to write (1..128) */
)
{
    DSTATUS stat = STA_NODISK;
    switch (drv) {
        case SDMMC_DRV_0:
            stat = sdmmc_disk_write(buff, sector, count, pSDMMC);
            return stat;
        break;
        case W25Q_DRV_1:
            stat = w25q_disk_write(buff, sector, count, pW25Q);
            return stat;
        break;
    }
	return RES_PARERR;

}
#endif


/*-----------------------------------------------------------------------*/
/* Miscellaneous drive controls other than data read/write               */
/*-----------------------------------------------------------------------*/

DRESULT disk_ioctl (
	BYTE drv,		/* Physical drive number (0) */
	BYTE cmd,		/* Control command code */
	void *buff		/* Pointer to the conrtol data */
)
{
    DSTATUS stat;
    switch (drv) {
        case SDMMC_DRV_0:
            stat = sdmmc_disk_ioctl(cmd, buff, pSDMMC);
            return stat;
        break;
        case W25Q_DRV_1:
            stat = w25q_disk_ioctl(cmd, buff, pW25Q);
            return stat;
        break;
    }
	return RES_PARERR;
}

DWORD get_fattime(void) {
    datetime_t t = {0, 0, 0, 0, 0, 0, 0};
    bool rc = rtc_get_datetime(&t);
    if (!rc) return 0;

    DWORD fattime = 0;
    // bit31:25
    // Year origin from the 1980 (0..127, e.g. 37 for 2017)
    uint8_t yr = t.year - 1980;
    fattime |= (0b01111111 & yr) << 25;
    // bit24:21
    // Month (1..12)
    uint8_t mo = t.month;
    fattime |= (0b00001111 & mo) << 21;
    // bit20:16
    // Day of the month (1..31)
    uint8_t da = t.day;
    fattime |= (0b00011111 & da) << 16;
    // bit15:11
    // Hour (0..23)
    uint8_t hr = t.hour;
    fattime |= (0b00011111 & hr) << 11;
    // bit10:5
    // Minute (0..59)
    uint8_t mi = t.min;
    fattime |= (0b00111111 & mi) << 5;
    // bit4:0
    // Second / 2 (0..29, e.g. 25 for 50)
    uint8_t sd = t.sec / 2;
    fattime |= (0b00011111 & sd);
    return fattime;
}
  • W25Q.c
#include "stdio.h"
#include "stdlib.h"
#include "W25Q.h"

uint8_t rxbuf[10];
uint8_t txbuf[10];

/*=================*/

const uint8_t i_uniqueid=0x4b;
const uint8_t i_page_program=0x02;
const uint8_t i_read_data=0x03;
const uint8_t i_fast_read_data=0x0b;
const uint8_t i_write_disable=0x04;
const uint8_t i_read_status_r1=0x05;
const uint8_t i_read_status_r2=0x35;
const uint8_t i_read_status_r3=0x15;
const uint8_t i_write_status_r1=0x01;
const uint8_t i_write_status_r2=0x31;
const uint8_t i_write_status_r3=0x11;
const uint8_t i_sector_erase=0x20;
const uint8_t i_block_erase_32k=0x52;
const uint8_t i_block_erase_64k=0xd8;
const uint8_t i_write_enable=0x06;
const uint8_t i_erase_chip=0xc7;

const uint8_t i_device_id=0x90;
const uint8_t i_JEDEC_ID=0x9f;

void w25q_spi_port_init(w25q_data_t *w25q) {
    gpio_set_dir(w25q->cs_pin, GPIO_OUT);
    gpio_put(w25q->cs_pin, 1);
    gpio_set_function(w25q->cs_pin,   GPIO_FUNC_SIO);
    gpio_set_function(W25Q_PIN_MISO, GPIO_FUNC_SPI);
    gpio_set_function(W25Q_PIN_SCK,  GPIO_FUNC_SPI);
    gpio_set_function(W25Q_PIN_MOSI, GPIO_FUNC_SPI);
        
    printf("\nThe actual baudrate(W25Q):%d\n",spi_init(w25q->spi, SPI_BAUDRATE_HIGH));

    w25q->spiInit=true;
}

void w25q_spi_cs_low(w25q_data_t *w25q) {
    gpio_put(w25q->cs_pin,0);
}
void w25q_spi_cs_high(w25q_data_t *w25q){
    gpio_put(w25q->cs_pin,1);
}
void w25q_send_cmd_read(uint8_t cmd, uint32_t address, uint8_t *buf, uint32_t len, bool is_fast, w25q_data_t *w25q) {
    uint8_t addr[4];
    int addr_len=3;
    addr[3] = 0x00;
    if (is_fast) addr_len=4;
    addr[0] = (address & 0x00ff0000) >> 16;
    addr[1] = (address & 0x0000ff00) >> 8;
    addr[2] = (address & 0x000000ff);
    w25q_spi_cs_low(w25q);
    spi_write_blocking(w25q->spi, &cmd, 1);
    spi_write_blocking(w25q->spi, addr, addr_len);
    spi_read_blocking(w25q->spi, 0x00, buf, len);
    w25q_spi_cs_high(w25q);
}

void w25q_send_cmd_write(uint8_t cmd, uint32_t address, uint8_t *buf, uint32_t len, w25q_data_t *w25q) {
    uint8_t addr[3];
    
    addr[0] = (address & 0x00ff0000) >> 16;
    addr[1] = (address & 0x0000ff00) >> 8;
    addr[2] = (address & 0x000000ff);
    w25q_write_enable(w25q);
    w25q_spi_cs_low(w25q);
    spi_write_blocking(w25q->spi, &cmd, 1);
    spi_write_blocking(w25q->spi, addr, 3);
    spi_write_blocking(w25q->spi, buf, len);
    w25q_spi_cs_high(w25q);

}

void w25q_send_cmd_addr(uint8_t cmd, uint32_t address, w25q_data_t *w25q) {
    uint8_t addr[3];
    addr[0] = (address & 0x00ff0000) >> 16;
    addr[1] = (address & 0x0000ff00) >> 8;
    addr[2] = (address & 0x000000ff);
    w25q_spi_cs_low(w25q);
    spi_write_blocking(w25q->spi, &cmd, 1);
    spi_write_blocking(w25q->spi, addr, 3);
    w25q_spi_cs_high(w25q);
}

void w25q_send_cmd(uint8_t cmd, uint8_t *buf, uint32_t len, w25q_data_t *w25q) {
    w25q_spi_cs_low(w25q);
    spi_write_blocking(w25q->spi, &cmd, 1);
    spi_read_blocking(w25q->spi, 0x00, buf, len);
    w25q_spi_cs_high(w25q);
}

void w25q_send_simple_cmd(uint8_t cmd, w25q_data_t *w25q) {
    w25q_spi_cs_low(w25q);
    spi_write_blocking(w25q->spi, &cmd, 1);
    w25q_spi_cs_high(w25q);
}

void w25q_write_enable(w25q_data_t *w25q) {
    w25q_send_simple_cmd(i_write_enable, w25q);
    sleep_ms(1);
}
void w25q_write_disable(w25q_data_t *w25q) {
    w25q_send_simple_cmd(i_write_disable, w25q);
    sleep_ms(1);
}

/*==================*/
DRESULT w25q_disk_initialize(spi_inst_t *spi, uint cs_pin, w25q_data_t *w25q) {
    w25q->spi = spi;
    w25q->cs_pin = cs_pin;

    if (!w25q->spiInit) w25q_spi_port_init(w25q);

    w25q_get_JEDEC_ID(w25q);
    w25q->lock = 1;
	sleep_ms(100);
	switch (w25q->jedec_id & 0x000000FF)
	{
	    case 0x20: // 	w25q512
		    w25q->blockCount = 1024;
		break;
	    case 0x19: // 	w25q256
		    w25q->blockCount = 512;
		break;
	    case 0x18: // 	w25q128
		    w25q->blockCount = 256;
		break;
	    case 0x17: //	w25q64
		    w25q->blockCount = 128;
		break;
	    case 0x16: //	w25q32
		    w25q->blockCount = 64;
		break;
        case 0x15: //	w25q16
            w25q->blockCount = 32;
            break;
        case 0x14: //	w25q80
            w25q->blockCount = 16;
            break;
        case 0x13: //	w25q40
            w25q->blockCount = 8;
        case 0x12: //	w25q20
            w25q->blockCount = 4;
            break;
        case 0x11: //	w25q10
            w25q->blockCount = 2;
            break;
        default:
            w25q->lock = 0;
            return false;
    }
	w25q->pageSize = 256;
	w25q->sectorSize = 0x1000;
	w25q->sectorCount = w25q->blockCount * 16;
	w25q->pageCount = (w25q->sectorCount * w25q->sectorSize) / w25q->pageSize;
	w25q->blockSize = w25q->sectorSize * 16;
	w25q->capacityKB = (w25q->sectorCount * w25q->sectorSize) / 1024;
	w25q_get_uid(w25q);
    w25q_read_status_register_1(w25q);
    w25q_read_status_register_2(w25q);
    w25q_read_status_register_3(w25q);
	w25q->lock = 0;
    w25q->Stat &= ~STA_NOINIT;
	return w25q->Stat;
}


void w25q_read_status_register_1(w25q_data_t *w25q){
    w25q_send_cmd(i_read_status_r1, &w25q->statusRegister1, 1, w25q);
}
void w25q_read_status_register_2(w25q_data_t *w25q){
    w25q_send_cmd(i_read_status_r2, &w25q->statusRegister2, 1, w25q);
}
void w25q_read_status_register_3(w25q_data_t *w25q){
    w25q_send_cmd(i_read_status_r3, &w25q->statusRegister3, 1, w25q);
}

void w25q_write_status_register_1(w25q_data_t *w25q){
    w25q_send_cmd(i_write_status_r1, &w25q->statusRegister1, 1, w25q);
}
void w25q_write_status_register_2(w25q_data_t *w25q){
    w25q_send_cmd(i_write_status_r2, &w25q->statusRegister2, 1, w25q);
}
void w25q_write_status_register_3(w25q_data_t *w25q){
    w25q_send_cmd(i_write_status_r3, &w25q->statusRegister3, 1, w25q);
}

void w25q_wait_for_write_end(w25q_data_t *w25q)
{
	sleep_ms(1);
	w25q_spi_cs_low(w25q);
	spi_write_blocking(w25q->spi, &i_read_status_r1,1);
	do
	{
		spi_read_blocking(w25q->spi, 0x00, &w25q->statusRegister1,1);
		sleep_ms(1);
	} while ((w25q->statusRegister1 & 0x01) == 0x01);
	w25q_spi_cs_high(w25q);
}

void w25q_erase_chip(w25q_data_t *w25q) {
    while (w25q->lock) sleep_ms(1);
    w25q->lock=1;
    w25q_write_enable(w25q);
    w25q_send_simple_cmd(i_erase_chip, w25q);
    w25q_wait_for_write_end(w25q);
    sleep_ms(10);
    w25q->lock=0;
}

void w25q_page_program(uint32_t page_addr, uint16_t offset, uint8_t *buf, uint32_t len, w25q_data_t *w25q) {
    while (w25q->lock) sleep_ms(1);
    w25q->lock=1;
    if (offset + len > w25q->pageSize) {
        len = w25q->pageSize - offset;
    }
    page_addr = (page_addr * w25q->pageSize) + offset;
    w25q_wait_for_write_end(w25q);
    w25q_write_enable(w25q);
    w25q_send_cmd_write(i_page_program, page_addr, buf, len, w25q);
    w25q_wait_for_write_end(w25q);
    sleep_ms(1);
    w25q->lock=0;
}
/*===========================*/
uint32_t w25_page_to_sector_address(uint32_t pageAddress, w25q_data_t *w25q)
{
	return ((pageAddress * w25q->pageSize) / w25q->sectorSize);
}
uint32_t w25q_page_to_block_address(uint32_t pageAddress, w25q_data_t *w25q)
{
	return ((pageAddress * w25q->pageSize) / w25q->blockSize);
}
uint32_t w25q_data_sector_to_block_address(uint32_t sectorAddress, w25q_data_t *w25q)
{
	return ((sectorAddress * w25q->sectorSize) / w25q->blockSize);
}
uint32_t w25q_sector_to_page_address(uint32_t sectorAddress, w25q_data_t *w25q)
{
	return (sectorAddress * w25q->sectorSize) / w25q->pageSize;
}
uint32_t w25q_block_to_page_address(uint32_t blockAddress, w25q_data_t *w25q)
{
	return (blockAddress * w25q->blockSize) / w25q->pageSize;
}
/*============================*/

void w25q_write_sector(uint32_t sect_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q) {
	if (offset >= w25q->sectorSize) return;
    if (offset + len  > w25q->sectorSize) 
		len = w25q->sectorSize - offset;
	uint32_t startPage;
	int32_t bytesToWrite;
	uint32_t localOffset;


    startPage = w25q_sector_to_page_address(sect_addr, w25q) + (offset / w25q->pageSize);
	localOffset = offset % w25q->pageSize;
    bytesToWrite = len;

	do
	{
        w25q_page_program(startPage, localOffset, buf, bytesToWrite, w25q);
		startPage++;
		bytesToWrite -= w25q->pageSize - localOffset;
		buf += w25q->pageSize - localOffset;
		localOffset = 0;
	} while (bytesToWrite > 0);

}

void w25q_write_block_64k(uint32_t blk_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q) {
	if ((len > w25q->blockSize) || (len == 0))
		len = w25q->blockSize;
	if (offset >= w25q->blockSize)
		return;
	uint32_t startPage;
	int32_t bytesToWrite;
	uint32_t localOffset;
	if ((offset + len) > w25q->blockSize)
		bytesToWrite = w25q->blockSize - offset;
	else
		bytesToWrite = len;
	startPage = w25q_block_to_page_address(blk_addr, w25q) + (offset / w25q->pageSize);
	localOffset = offset % w25q->pageSize;
	do
	{
		w25q_page_program(startPage, localOffset, buf, len, w25q);
		startPage++;
		bytesToWrite -= w25q->pageSize - localOffset;
		buf += w25q->pageSize - localOffset;
		localOffset = 0;
	} while (bytesToWrite > 0);
   
}

DRESULT w25q_disk_write(
	const BYTE *buff,	/* Ponter to the data to write */
	LBA_t sector,		/* Start sector number (LBA) */
	UINT count, 			/* Number of sectors to write (1..128) */
    w25q_data_t *w25q
) 
{
    BYTE *tbuf=(BYTE*)buff;
    while(count > 1)
    {
        w25q_sector_erase(sector, w25q);
        w25q_write_sector(sector, 0, tbuf, w25q->sectorSize, w25q);
        count--;
        tbuf += w25q->sectorSize;
        sector++;
    }
    if (count == 1)
    {
        w25q_sector_erase(sector, w25q);
        w25q_write_sector(sector, 0, tbuf, w25q->sectorSize, w25q);
        count--;
    }
	
	return count? RES_ERROR: RES_OK;
}

void w25q_read_bytes(uint32_t address, uint8_t *buf, uint32_t len, w25q_data_t *w25q) {
	while (w25q->lock == 1) sleep_ms(1);
	w25q->lock = 1;
    w25q_send_cmd_read(i_fast_read_data, address, buf, len, true, w25q);
	sleep_ms(1);
	w25q->lock = 0;
}

void w25q_read_page(uint32_t page_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q) {
	while (w25q->lock == 1) sleep_ms(1);
	w25q->lock = 1;
    if (offset >= w25q->pageSize) return;
	if ((offset + len) >= w25q->pageSize)
		len = w25q->pageSize - offset;
	page_addr = page_addr * w25q->pageSize + offset;
    w25q_send_cmd_read(i_fast_read_data, page_addr, buf, len, true, w25q);
	
	sleep_ms(1);
	w25q->lock = 0;
}

DRESULT w25q_read_sector(uint32_t sect_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q) {
	
    if (offset >= w25q->sectorSize) return RES_ERROR;
    if (offset + len > w25q->sectorSize)
		len = w25q->sectorSize - offset;
	uint32_t startPage;
	int32_t bytesToRead;
	uint32_t localOffset;
    bytesToRead = len;
	
    startPage = w25q_sector_to_page_address(sect_addr, w25q) + (offset / w25q->pageSize);
	localOffset = offset % w25q->pageSize;
	do
	{
		w25q_read_page(startPage, localOffset, buf, bytesToRead, w25q);
    
		startPage++;
		bytesToRead -= w25q->pageSize - localOffset;
		buf += w25q->pageSize - localOffset;
		localOffset = 0;
	} while (bytesToRead > 0);
    return RES_OK;

}
void w25q_read_block(uint32_t blk_addr, uint32_t offset, uint8_t *buf, uint32_t len, w25q_data_t *w25q) {
	if (offset+len > w25q->blockSize)
		len = w25q->blockSize-offset;

	uint32_t startPage;
	int32_t bytesToRead;
	uint32_t localOffset;
    bytesToRead = len;

	startPage = w25q_block_to_page_address(blk_addr, w25q) + (offset / w25q->pageSize);
	localOffset = offset % w25q->pageSize;
	do
	{
		w25q_read_page(startPage, localOffset, buf, bytesToRead, w25q);
		startPage++;
		bytesToRead -= w25q->pageSize - localOffset;
		buf += w25q->pageSize - localOffset;
		localOffset = 0;
	} while (bytesToRead > 0);

}


void w25q_sector_erase(uint32_t sect_addr, w25q_data_t *w25q) {
    while(w25q->lock) sleep_ms(1);
    w25q->lock=1;
    sect_addr = sect_addr * w25q->sectorSize;
    w25q_wait_for_write_end(w25q);
    w25q_write_enable(w25q);
    w25q_send_cmd_addr(i_sector_erase, sect_addr, w25q);
    w25q_wait_for_write_end(w25q);
    sleep_ms(1);
    w25q->lock=0;
}
void w25q_block_erase_32k(uint32_t blk_addr, w25q_data_t *w25q) {
    while(w25q->lock) sleep_ms(1);
    w25q->lock=1;
    blk_addr = blk_addr * w25q->sectorSize * 8;
    w25q_wait_for_write_end(w25q);
    w25q_write_enable(w25q);
    w25q_send_cmd_addr(i_block_erase_32k, blk_addr, w25q);
    w25q_wait_for_write_end(w25q);
    sleep_ms(1);
    w25q->lock=0;
}
void w25q_block_erase_64k(uint32_t blk_addr, w25q_data_t *w25q) {
    while(w25q->lock) sleep_ms(1);
    w25q->lock=1;
    blk_addr = blk_addr * w25q->sectorSize * 16;
    w25q_wait_for_write_end(w25q);
    w25q_write_enable(w25q);
    w25q_send_cmd_addr(i_block_erase_64k, blk_addr, w25q);
    w25q_wait_for_write_end(w25q);
    sleep_ms(1);
    w25q->lock=0;
}
void w25q_get_manufacter_device_id(uint8_t *mid, w25q_data_t *w25q){
    assert(w25q->spi);
    w25q_send_cmd_read(i_device_id, 0x000000, mid, 2, false, w25q);
}


void w25q_get_JEDEC_ID(w25q_data_t *w25q) {
    uint8_t temp[3];
    w25q_send_cmd(i_JEDEC_ID, temp, 3, w25q);
    w25q->jedec_id = ((uint32_t)temp[0] << 16) | ((uint32_t)temp[1] << 8) | (uint32_t)temp[2];
}
void w25q_get_uid(w25q_data_t *w25q) {
    assert(w25q->spi);
    txbuf[0]= 0x4b;
    txbuf[1] = 0x00; txbuf[2] = 0x00; txbuf[3] = 0x00;txbuf[4]=0x00;
    w25q_spi_cs_low(w25q);
    spi_write_blocking(w25q->spi, txbuf, 5);
    spi_read_blocking(w25q->spi, 0x00, w25q->uuid, 8);
    w25q_spi_cs_high(w25q);
}

DRESULT w25q_disk_ioctl (
	BYTE cmd,		/* Control code */
	void *buff,		/* Buffer to send/receive control data */
    w25q_data_t *w25q
)
{
	DRESULT res = RES_ERROR;
	
    switch(cmd) {
    case CTRL_SYNC:
    	res = RES_OK;
    	break;
    case GET_SECTOR_SIZE:
		*(WORD*)buff = (WORD)w25q->sectorSize; // in f_mkfs() [WORD ss] 
        res = RES_OK;
		break;
    case GET_BLOCK_SIZE:
		
        *(DWORD*)buff = w25q->blockSize;
        res = RES_OK;
		
    	break;
    case GET_SECTOR_COUNT:
		
        *(DWORD*)buff = w25q->sectorCount;
        res = RES_OK;
		
    	break;
    default:
    	res = RES_PARERR;
    	break;
    }
    return res;
}
  • W25q.h
#ifndef W25Q_H
#define W25Q_H
#include "stdio.h"
#include "stdlib.h"
#include "pico/stdlib.h"
#include "hardware/spi.h"
#include "ff.h"
#include "ffconf.h"
#include "diskio.h"


/* W25Q SPI pins*/
#define W25Q_SPI_PORT spi0
#define W25Q_PIN_MISO 16
#define W25Q_PIN_SCK  18
#define W25Q_PIN_MOSI 19
#define W25Q_PIN_CS 17
/* ====================== */

typedef struct{
    spi_inst_t *spi;
    uint        cs_pin;
    uint8_t     uuid[8];
    uint32_t    jedec_id;
    uint32_t    blockCount;
    uint32_t    pageCount;
    uint32_t    sectorCount;
    uint16_t    pageSize;
    uint32_t    sectorSize;
    uint32_t    blockSize;
    uint8_t     statusRegister1;
    uint8_t     statusRegister2;
    uint8_t     statusRegister3;
    uint32_t    capacityKB;
    uint8_t     lock;
    bool        spiInit;
    DRESULT     Stat;
}w25q_data_t;


DRESULT w25q_disk_initialize(spi_inst_t *spi, uint cs_pin, w25q_data_t *w25q);
void w25q_get_manufacter_device_id(uint8_t *mid, w25q_data_t *w25q);
void w25q_get_JEDEC_ID(w25q_data_t *w25q);
void w25q_erase_chip(w25q_data_t *w25q);
void w25q_page_program(uint32_t page_addr, uint16_t offset, uint8_t *buf, uint32_t len, w25q_data_t *w25q);
void w25q_write_sector(uint32_t sect_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q);
void w25q_write_block_64k(uint32_t blk_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q);
void w25q_read_bytes(uint32_t address, uint8_t *buf, uint32_t len, w25q_data_t *w25q);
void w25q_read_page(uint32_t page_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q);
DRESULT w25q_read_sector(uint32_t sect_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q);
void w25q_read_block(uint32_t blk_addr, uint32_t offset, uint8_t *buf, uint32_t len, w25q_data_t *w25q);
//void w25q_read_data(uint32_t address, uint8_t *buf, uint32_t len);
//void w25q_fast_read_data(uint32_t address, uint8_t *buf, uint32_t len);
void w25q_read_status_register_1(w25q_data_t *w25q);
void w25q_read_status_register_2(w25q_data_t *w25q);
void w25q_read_status_register_3(w25q_data_t *w25q);
void w25q_write_status_register_1(w25q_data_t *w25q);
void w25q_write_status_register_2(w25q_data_t *w25q);
void w25q_write_status_register_3(w25q_data_t *w25q);
void w25q_sector_erase(uint32_t sect_addr, w25q_data_t *w25q);
void w25q_block_erase_32k(uint32_t blk_addr,w25q_data_t *w25q);
void w25q_block_erase_64k(uint32_t blk_addr, w25q_data_t *w25q);
void w25q_get_uid(w25q_data_t *w25q);
void w25q_write_enable(w25q_data_t *w25q);
void w25q_write_diable(w25q_data_t *w25q);
DRESULT w25q_disk_write(const BYTE *buff, LBA_t sector, UINT count,w25q_data_t *w25q);
DRESULT w25q_disk_ioctl(BYTE cmd, void *buff, w25q_data_t *w25q);

#endif

  • spi_sdmmc.c
/*
This library is derived from ChaN's FatFs - Generic FAT Filesystem Module.
*/
#include "stdio.h"
#include "stdlib.h"
#include "pico/stdlib.h"
#include "spi_sdmmc.h"


#define SDMMC_CD 0 // card detect
#define SDMMC_WP 0 // write protected

static uint8_t dummy_block[512];


/* sdmmc spi port initialize*/
void sdmmc_spi_port_init(sdmmc_data_t *sdmmc)
{
	spi_init(sdmmc->spiPort, SPI_BAUDRATE_LOW);
	gpio_set_function(SDMMC_PIN_MISO, GPIO_FUNC_SPI);
	gpio_set_function(sdmmc->csPin, GPIO_FUNC_SIO);
	gpio_set_function(SDMMC_PIN_SCK, GPIO_FUNC_SPI);
	gpio_set_function(SDMMC_PIN_MOSI, GPIO_FUNC_SPI);
	gpio_set_dir(sdmmc->csPin, GPIO_OUT);
	gpio_put(sdmmc->csPin, 1); // deselect

	sdmmc->spiInit = true; // alreadily initialized
}

/* config spi dma*/
#ifdef __SPI_SDMMC_DMA
void config_spi_dma(sdmmc_data_t *sdmmc)
{
	sdmmc->read_dma_ch = dma_claim_unused_channel(true);
	sdmmc->write_dma_ch = dma_claim_unused_channel(true);
	sdmmc->dma_rc = dma_channel_get_default_config(sdmmc->read_dma_ch);
	sdmmc->dma_wc = dma_channel_get_default_config(sdmmc->write_dma_ch);
	channel_config_set_transfer_data_size(&(sdmmc->dma_rc), DMA_SIZE_8);
	channel_config_set_transfer_data_size(&(sdmmc->dma_wc), DMA_SIZE_8);
	channel_config_set_read_increment(&(sdmmc->dma_rc), false);
	channel_config_set_write_increment(&(sdmmc->dma_rc), true);
	channel_config_set_read_increment(&(sdmmc->dma_wc), true);
	channel_config_set_write_increment(&(sdmmc->dma_wc), false);
	channel_config_set_dreq(&(sdmmc->dma_rc), spi_get_dreq(sdmmc->spiPort, false));
	channel_config_set_dreq(&(sdmmc->dma_wc), spi_get_dreq(sdmmc->spiPort, true));

	for (int i = 0; i < 512; i++)
		dummy_block[i] = 0xFF;

	dma_channel_configure(sdmmc->read_dma_ch,
						  &(sdmmc->dma_rc),
						  NULL,
						  &spi_get_hw(sdmmc->spiPort)->dr,
						  sdmmc->sectSize, false);
	dma_channel_configure(sdmmc->write_dma_ch,
						  &(sdmmc->dma_wc),
						  &spi_get_hw(sdmmc->spiPort)->dr,
						  NULL,
						  sdmmc->sectSize, false);
	sdmmc->dmaInit = true;
}
#endif

/* set spi cs low (select)*/
void sdmmc_spi_cs_low(sdmmc_data_t *sdmmc)
{
	gpio_put(sdmmc->csPin, 0);
}
/* set spi cs high (deselect)*/
void sdmmc_spi_cs_high(sdmmc_data_t *sdmmc)
{
	gpio_put(sdmmc->csPin, 1);
}
/* Initialize SDMMC SPI interface */
static void sdmmc_init_spi(sdmmc_data_t *sdmmc)
{
	sdmmc_spi_port_init(sdmmc); // if not initialized, init it
#ifdef __SPI_SDMMC_DMA
	if (!sdmmc->dmaInit)
		config_spi_dma(sdmmc);
#endif

	sleep_ms(10);
}

/* Receive a sector data (512 bytes) */
static void sdmmc_read_spi_dma(
	BYTE *buff, /* Pointer to data buffer */
	UINT btr,	/* Number of bytes to receive (even number) */
	sdmmc_data_t *sdmmc)
{
#ifdef __SPI_SDMMC_DMA
	dma_channel_set_read_addr(sdmmc->write_dma_ch, dummy_block, false);
	dma_channel_set_trans_count(sdmmc->write_dma_ch, btr, false);

	dma_channel_set_write_addr(sdmmc->read_dma_ch, buff, false);
	dma_channel_set_trans_count(sdmmc->read_dma_ch, btr, false);

	dma_start_channel_mask((1u << (sdmmc->read_dma_ch)) | (1u << (sdmmc->write_dma_ch)));
	dma_channel_wait_for_finish_blocking(sdmmc->read_dma_ch);
#else
	spi_read_blocking(sdmmc->spiPort, 0xFF, buff, btr);
#endif
}

#if FF_FS_READONLY == 0
/* Send a sector data (512 bytes) */
static void sdmmc_write_spi_dma(
	const BYTE *buff, /* Pointer to the data */
	UINT btx,		  /* Number of bytes to send (even number) */
	sdmmc_data_t *sdmmc)
{
#ifdef __SPI_SDMMC_DMA
	dma_channel_set_read_addr(sdmmc->write_dma_ch, buff, false);
	dma_channel_set_trans_count(sdmmc->write_dma_ch, btx, false);
	dma_channel_start(sdmmc->write_dma_ch);
	dma_channel_wait_for_finish_blocking(sdmmc->write_dma_ch);
#else
	spi_write_blocking(sdmmc->spiPort, buff, btx);
#endif
}
#endif

/*-----------------------------------------------------------------------*/
/* Wait for card ready                                                   */
/*-----------------------------------------------------------------------*/
static int sdmmc_wait_ready(uint timeout, sdmmc_data_t *sdmmc)
{
	uint8_t dst;
	absolute_time_t timeout_time = make_timeout_time_ms(timeout);
	do
	{
		spi_read_blocking(sdmmc->spiPort, 0xFF, &dst, 1);
	} while (dst != 0xFF && 0 < absolute_time_diff_us(get_absolute_time(), timeout_time)); /* Wait for card goes ready or timeout */

	return (dst == 0xFF) ? 1 : 0;
}

/*-----------------------------------------------------------------------*/
/* Deselect card and release SPI                                         */
/*-----------------------------------------------------------------------*/
static void sdmmc_deselect(sdmmc_data_t *sdmmc)
{
	uint8_t src = 0xFF;
	sdmmc_spi_cs_high(sdmmc);
	spi_write_blocking(sdmmc->spiPort, &src, 1);
}

/*-----------------------------------------------------------------------*/
/* Select card and wait for ready                                        */
/*-----------------------------------------------------------------------*/
static int sdmmc_select(sdmmc_data_t *sdmmc) /* 1:OK, 0:Timeout */
{
	uint8_t src = 0xFF;
	sdmmc_spi_cs_low(sdmmc);
	spi_write_blocking(sdmmc->spiPort, &src, 1);
	if (sdmmc_wait_ready(500, sdmmc))
		return 1; /* Wait for card ready */
	sdmmc_deselect(sdmmc);
	return 0; /* Timeout */
}

/*-----------------------------------------------------------------------*/
/* Receive a data packet from the MMC                                    */
/*-----------------------------------------------------------------------*/
// static
int sdmmc_read_datablock(			 /* 1:OK, 0:Error */
						 BYTE *buff, /* Data buffer */
						 UINT btr,	 /* Data block length (byte) */
						 sdmmc_data_t *sdmmc)
{
	BYTE token;
	absolute_time_t timeout_time = make_timeout_time_ms(200);
	do
	{ /* Wait for DataStart token in timeout of 200ms */
		spi_read_blocking(sdmmc->spiPort, 0xFF, &token, 1);
	} while ((token == 0xFF) && 0 < absolute_time_diff_us(get_absolute_time(), timeout_time));
	if (token != 0xFE)
		return 0; /* Function fails if invalid DataStart token or timeout */

	sdmmc_read_spi_dma(buff, btr, sdmmc);
	// Discard CRC
	spi_read_blocking(sdmmc->spiPort, 0xFF, &token, 1);
	spi_read_blocking(sdmmc->spiPort, 0xFF, &token, 1);
	return 1; // Function succeeded
}

/*-----------------------------------------------------------------------*/
/* Send a data packet to the MMC                                         */
/*-----------------------------------------------------------------------*/
#if FF_FS_READONLY == 0
// static
int sdmmc_write_datablock(					/* 1:OK, 0:Failed */
						  const BYTE *buff, /* Ponter to 512 byte data to be sent */
						  BYTE token,		/* Token */
						  sdmmc_data_t *sdmmc)
{
	BYTE resp;
	if (!sdmmc_wait_ready(500, sdmmc))
		return 0; /* Wait for card ready */
	// Send token : 0xFE--single block, 0xFC -- multiple block write start, 0xFD -- StopTrans
	spi_write_blocking(sdmmc->spiPort, &token, 1);
	if (token != 0xFD)
	{										   /* Send data if token is other than StopTran */
		sdmmc_write_spi_dma(buff, 512, sdmmc); /* Data */

		token = 0xFF;
		spi_write_blocking(sdmmc->spiPort, &token, 1); // Dummy CRC
		spi_write_blocking(sdmmc->spiPort, &token, 1);

		spi_read_blocking(sdmmc->spiPort, 0xFF, &resp, 1);
		// receive response token: 0x05 -- accepted, 0x0B -- CRC error, 0x0C -- Write Error
		if ((resp & 0x1F) != 0x05)
			return 0; /* Function fails if the data packet was not accepted */
	}
	return 1;
}
#endif

/*-----------------------------------------------------------------------*/
/* Send a command packet to the MMC                                      */
/*-----------------------------------------------------------------------*/
//static
BYTE sdmmc_send_cmd(			  /* Return value: R1 resp (bit7==1:Failed to send) */
						   BYTE cmd,  /* Command index */
						   DWORD arg, /* Argument */
						   sdmmc_data_t *sdmmc)
{
	BYTE n, res;
	BYTE tcmd[5];

	if (cmd & 0x80)
	{ /* Send a CMD55 prior to ACMD<n> */
		cmd &= 0x7F;
		res = sdmmc_send_cmd(CMD55, 0, sdmmc);
		if (res > 1)
			return res;
	}

	/* Select the card and wait for ready except to stop multiple block read */
	if (cmd != CMD12)
	{
		sdmmc_deselect(sdmmc);
		if (!sdmmc_select(sdmmc))
			return 0xFF;
	}

	/* Send command packet */
	tcmd[0] = 0x40 | cmd;		 // 0 1 cmd-index(6) --> 01xxxxxx(b)
	tcmd[1] = (BYTE)(arg >> 24); // 32 bits argument
	tcmd[2] = (BYTE)(arg >> 16);
	tcmd[3] = (BYTE)(arg >> 8);
	tcmd[4] = (BYTE)arg;
	spi_write_blocking(sdmmc->spiPort, tcmd, 5);
	n = 0x01; /* Dummy CRC + Stop */
	if (cmd == CMD0)
		n = 0x95; /* Valid CRC for CMD0(0) */
	if (cmd == CMD8)
		n = 0x87; /* Valid CRC for CMD8(0x1AA) */

	spi_write_blocking(sdmmc->spiPort, &n, 1);

	/* Receive command resp */
	if (cmd == CMD12)
		spi_read_blocking(sdmmc->spiPort, 0xFF, &res, 1); /* Diacard following one byte when CMD12 */
	n = 10;												  /* Wait for response (10 bytes max) */
	do
	{
		spi_read_blocking(sdmmc->spiPort, 0xFF, &res, 1);
	} while ((res & 0x80) && --n);

	return res; /* Return received response */
}

/*-----------------------------------------------------------------------*/
/* Initialize disk drive                                                 */
/*-----------------------------------------------------------------------*/
DSTATUS sdmmc_init(sdmmc_data_t *sdmmc)
{
	BYTE n, cmd, ty, src, ocr[4];

	sdmmc->Stat = STA_NOINIT;
	// low baudrate
	spi_set_baudrate(sdmmc->spiPort, SPI_BAUDRATE_LOW);
	src = 0xFF;
	sdmmc_spi_cs_low(sdmmc);
	for (n = 10; n; n--)
		spi_write_blocking(sdmmc->spiPort, &src, 1); // Send 80 dummy clocks
	sdmmc_spi_cs_high(sdmmc);

	ty = 0;
	if (sdmmc_send_cmd(CMD0, 0, sdmmc) == 1)
	{ /* Put the card SPI/Idle state, R1 bit0=1*/
		absolute_time_t timeout_time = make_timeout_time_ms(1000);
		if (sdmmc_send_cmd(CMD8, 0x1AA, sdmmc) == 1)
		{													 /* SDv2? */
			spi_read_blocking(sdmmc->spiPort, 0xFF, ocr, 4); // R7(5 bytes): R1 read by sdmmc_send_cmd, Get the other 32 bit return value of R7 resp
			if (ocr[2] == 0x01 && ocr[3] == 0xAA)
			{ /* Is the card supports vcc of 2.7-3.6V? */
				while ((0 < absolute_time_diff_us(get_absolute_time(), timeout_time)) && sdmmc_send_cmd(ACMD41, 1UL << 30, sdmmc))
					; /* Wait for end of initialization with ACMD41(HCS) */
				if ((0 < absolute_time_diff_us(get_absolute_time(), timeout_time)) && sdmmc_send_cmd(CMD58, 0, sdmmc) == 0)
				{ /* Check CCS bit in the OCR */
					spi_read_blocking(sdmmc->spiPort, 0xFF, ocr, 4);
					ty = (ocr[0] & 0x40) ? CT_SDC2 | CT_BLOCK : CT_SDC2; /* Card id SDv2 */
				}
			}
		}
		else
		{ /* Not SDv2 card */
			if (sdmmc_send_cmd(ACMD41, 0, sdmmc) <= 1)
			{ /* SDv1 or MMC? */
				ty = CT_SDC1;
				cmd = ACMD41; /* SDv1 (ACMD41(0)) */
			}
			else
			{
				ty = CT_MMC3;
				cmd = CMD1; /* MMCv3 (CMD1(0)) */
			}
			while ((0 < absolute_time_diff_us(get_absolute_time(), timeout_time)) && sdmmc_send_cmd(cmd, 0, sdmmc))
				;																										   /* Wait for end of initialization */
			if (!(0 < absolute_time_diff_us(get_absolute_time(), timeout_time)) || sdmmc_send_cmd(CMD16, 512, sdmmc) != 0) /* Set block length: 512 */
				ty = 0;
		}
	}
	sdmmc->cardType = ty; /* Card type */
	sdmmc_deselect(sdmmc);
	if (ty)
	{ /* OK */
		// high baudrate
		printf("\nThe actual baudrate(SD/MMC):%d\n",spi_set_baudrate(sdmmc->spiPort, SPI_BAUDRATE_HIGH)); // speed high
		sdmmc->sectSize = 512;
		sdmmc->Stat &= ~STA_NOINIT; /* Clear STA_NOINIT flag */
	}
	else
	{ /* Failed */
		sdmmc->Stat = STA_NOINIT;
	}

	return sdmmc->Stat;
}

/* sdmmc_disk_initizlize, sdmmc_disk_read, sdmmc_disk_write, sdmmc_disk_status, sdmmc_disk_ioctl*/

/* sdmmc_disk_initialize*/
DSTATUS sdmmc_disk_initialize(sdmmc_data_t *sdmmc)
{
	if (!sdmmc->spiInit)
		sdmmc_init_spi(sdmmc); /* Initialize SPI */
	DSTATUS stat = sdmmc_init(sdmmc);

	return stat;
}
/* sdmmc disk status*/
DSTATUS sdmmc_disk_status(sdmmc_data_t *sdmmc)
{
	return sdmmc->Stat;
}

/* sdmmc disk read*/
DSTATUS sdmmc_disk_read(
	BYTE *buff,	  /* Pointer to the data buffer to store read data */
	LBA_t sector, /* Start sector number (LBA) */
	UINT count,	  /* Number of sectors to read (1..128) */
	sdmmc_data_t *sdmmc)
{
	DWORD sect = (DWORD)(sector);

	if (!count)
		return RES_PARERR; /* Check parameter */
	if (sdmmc->Stat & STA_NOINIT)
		return RES_NOTRDY; /* Check if drive is ready */

	if (!(sdmmc->cardType & CT_BLOCK))
		sect *= 512; /* LBA ot BA conversion (byte addressing cards) */
	if (count == 1)
	{												  /* Single sector read */
		if ((sdmmc_send_cmd(CMD17, sect, sdmmc) == 0) /* READ_SINGLE_BLOCK */
			&& sdmmc_read_datablock(buff, 512, sdmmc))
		{
			count = 0;
		}
	}
	else
	{ /* Multiple sector read */
		if (sdmmc_send_cmd(CMD18, sect, sdmmc) == 0)
		{ /* READ_MULTIPLE_BLOCK */
			do
			{
				if (!sdmmc_read_datablock(buff, 512, sdmmc))
					break;
				buff += 512;
			} while (--count);
			sdmmc_send_cmd(CMD12, 0, sdmmc); /* STOP_TRANSMISSION */
		}
	}
	sdmmc_deselect(sdmmc); // sdmmc_select() is called in function sdmmc_send_cmd()

	return count ? RES_ERROR : RES_OK; /* Return result */
}

DSTATUS sdmmc_disk_write(
	const BYTE *buff, /* Ponter to the data to write */
	LBA_t sector,	  /* Start sector number (LBA) */
	UINT count,		  /* Number of sectors to write (1..128) */
	sdmmc_data_t *sdmmc)
{
	DWORD sect = (DWORD)sector;
	if (!count)
		return RES_PARERR; /* Check parameter */
	if (sdmmc->Stat & STA_NOINIT)
		return RES_NOTRDY; /* Check drive status */
	if (sdmmc->Stat & STA_PROTECT)
		return RES_WRPRT; /* Check write protect */

	if (!(sdmmc->cardType & CT_BLOCK))
		sect *= 512; /* LBA ==> BA conversion (byte addressing cards) */

	if (count == 1)
	{												  /* Single sector write */
		if ((sdmmc_send_cmd(CMD24, sect, sdmmc) == 0) /* WRITE_BLOCK */
			&& sdmmc_write_datablock(buff, 0xFE, sdmmc))
		{
			count = 0;
		}
	}
	else
	{ /* Multiple sector write */
		if (sdmmc->cardType & CT_SDC)
			sdmmc_send_cmd(ACMD23, count, sdmmc); /* Predefine number of sectors */
		if (sdmmc_send_cmd(CMD25, sect, sdmmc) == 0)
		{ /* WRITE_MULTIPLE_BLOCK */
			do
			{
				if (!sdmmc_write_datablock(buff, 0xFC, sdmmc))
					break;
				buff += 512;
			} while (--count);
			if (!sdmmc_write_datablock(0, 0xFD, sdmmc))
				count = 1; /* STOP_TRAN token */
		}
	}
	sdmmc_deselect(sdmmc); // sdmmc_select() is called in function sdmmc_send_cmd

	return count ? RES_ERROR : RES_OK; /* Return result */
}

/* sdmmc disk ioctl*/
DSTATUS sdmmc_disk_ioctl(
	BYTE cmd,	/* Control command code */
	void *buff, /* Pointer to the conrtol data */
	sdmmc_data_t *sdmmc)
{
	DRESULT res;
	BYTE n, csd[16];
	DWORD st, ed, csize;
	LBA_t *dp;

	BYTE src = 0xFF;

	if (sdmmc->Stat & STA_NOINIT)
		return RES_NOTRDY; /* Check if drive is ready */

	res = RES_ERROR;
	switch (cmd)
	{
	case CTRL_SYNC: /* Wait for end of internal write process of the drive */
		if (sdmmc_select(sdmmc))
			res = RES_OK;
		break;
	case GET_SECTOR_COUNT: /* Get drive capacity in unit of sector (DWORD) */
		if ((sdmmc_send_cmd(CMD9, 0, sdmmc) == 0) && sdmmc_read_datablock(csd, 16, sdmmc))
		{
			if ((csd[0] >> 6) == 1)
			{ /* SDC CSD ver 2 */
				csize = csd[9] + ((WORD)csd[8] << 8) + ((DWORD)(csd[7] & 63) << 16) + 1;
				*(LBA_t *)buff = csize << 10;
			}
			else
			{ /* SDC CSD ver 1 or MMC */
				n = (csd[5] & 15) + ((csd[10] & 128) >> 7) + ((csd[9] & 3) << 1) + 2;
				csize = (csd[8] >> 6) + ((WORD)csd[7] << 2) + ((WORD)(csd[6] & 3) << 10) + 1;
				*(LBA_t *)buff = csize << (n - 9);
			}
			res = RES_OK;
		}
		break;
	case GET_SECTOR_SIZE: // FF_MAX_SS != FX_MIN_SS
		//*(WORD*)buff=512; // SDHC, SDXC sector size is 512
		*(WORD *)buff = sdmmc->sectSize;

		res = RES_OK;
		break;
	case GET_BLOCK_SIZE: /* Get erase block size in unit of sector (DWORD) */
		if (sdmmc->cardType & CT_SDC2)
		{ /* SDC ver 2+ */
			if (sdmmc_send_cmd(ACMD13, 0, sdmmc) == 0)
			{ /* Read SD status */
				spi_write_blocking(sdmmc->spiPort, &src, 1);
				if (sdmmc_read_datablock(csd, 16, sdmmc))
				{ /* Read partial block */
					for (n = 64 - 16; n; n--)
						spi_write_blocking(sdmmc->spiPort, &src, 1); // xchg_spi(0xFF);	/* Purge trailing data */
					*(DWORD *)buff = 16UL << (csd[10] >> 4);
					res = RES_OK;
				}
			}
		}
		else
		{ /* SDC ver 1 or MMC */
			if ((sdmmc_send_cmd(CMD9, 0, sdmmc) == 0) && sdmmc_read_datablock(csd, 16, sdmmc))
			{ /* Read CSD */
				if (sdmmc->cardType & CT_SDC1)
				{ /* SDC ver 1.XX */
					*(DWORD *)buff = (((csd[10] & 63) << 1) + ((WORD)(csd[11] & 128) >> 7) + 1) << ((csd[13] >> 6) - 1);
				}
				else
				{ /* MMC */
					*(DWORD *)buff = ((WORD)((csd[10] & 124) >> 2) + 1) * (((csd[11] & 3) << 3) + ((csd[11] & 224) >> 5) + 1);
				}
				res = RES_OK;
			}
		}
		break;

	case CTRL_TRIM: /* Erase a block of sectors (used when _USE_ERASE == 1) */
		if (!(sdmmc->cardType & CT_SDC))
			break; /* Check if the card is SDC */
		if (sdmmc_disk_ioctl(MMC_GET_CSD, csd, sdmmc))
			break; /* Get CSD */
		if (!(csd[10] & 0x40))
			break; /* Check if ERASE_BLK_EN = 1 */
		dp = buff;
		st = (DWORD)dp[0];
		ed = (DWORD)dp[1]; /* Load sector block */
		if (!(sdmmc->cardType & CT_BLOCK))
		{
			st *= 512;
			ed *= 512;
		}
		if (sdmmc_send_cmd(CMD32, st, sdmmc) == 0 && sdmmc_send_cmd(CMD33, ed, sdmmc) == 0 && sdmmc_send_cmd(CMD38, 0, sdmmc) == 0 && sdmmc_wait_ready(30000, sdmmc))
		{				  /* Erase sector block */
			res = RES_OK; /* FatFs does not check result of this command */
		}
		break;

		/* Following commands are never used by FatFs module */

	case MMC_GET_TYPE: /* Get MMC/SDC type (BYTE) */
		*(BYTE *)buff = sdmmc->cardType;
		res = RES_OK;
		break;

	case MMC_GET_CSD: /* Read CSD (16 bytes) */
		if (sdmmc_send_cmd(CMD9, 0, sdmmc) == 0 && sdmmc_read_datablock((BYTE *)buff, 16, sdmmc))
		{ /* READ_CSD */
			res = RES_OK;
		}
		break;

	case MMC_GET_CID: /* Read CID (16 bytes) */
		if (sdmmc_send_cmd(CMD10, 0, sdmmc) == 0 && sdmmc_read_datablock((BYTE *)buff, 16, sdmmc))
		{ /* READ_CID */
			res = RES_OK;
		}
		break;

	case MMC_GET_OCR: /* Read OCR (4 bytes) */
		if (sdmmc_send_cmd(CMD58, 0, sdmmc) == 0)
		{ /* READ_OCR */
			for (n = 0; n < 4; n++)
				*(((BYTE *)buff) + n) = spi_write_blocking(sdmmc->spiPort, &src, 1); // xchg_spi(0xFF);
			res = RES_OK;
		}
		break;

	case MMC_GET_SDSTAT: /* Read SD status (64 bytes) */
		if (sdmmc_send_cmd(ACMD13, 0, sdmmc) == 0)
		{ /* SD_STATUS */
			spi_write_blocking(sdmmc->spiPort, &src, 1);
			if (sdmmc_read_datablock((BYTE *)buff, 64, sdmmc))
				res = RES_OK;
		}
		break;

	default:
		res = RES_PARERR;
	}

	sdmmc_deselect(sdmmc); // sdmmc_select() is called in function sdmmc_send_cmd()

	return res;
}

  • spi_sdmmc.h
/*
This library is derived from ChaN's FatFs - Generic FAT Filesystem Module.
*/
#ifndef SPI_SDMMC_H
#define SPI_SDMMC_H
#include "hardware/spi.h"
#include "hardware/dma.h"
#include "ff.h"
#include "diskio.h"

//#define __SPI_SDMMC_DMA

/* SDMMC SPI pins*/
#define SDMMC_SPI_PORT spi1
#define SDMMC_PIN_MISO 12
#define SDMMC_PIN_CS   13
#define SDMMC_PIN_SCK  14
#define SDMMC_PIN_MOSI 15
/* ====================== */

/* MMC/SD command */
#define CMD0 (0)		   /* GO_IDLE_STATE */
#define CMD1 (1)		   /* SEND_OP_COND (MMC) */
#define ACMD41 (0x80 + 41) /* SEND_OP_COND (SDC) */
#define CMD8 (8)		   /* SEND_IF_COND */
#define CMD9 (9)		   /* SEND_CSD */
#define CMD10 (10)		   /* SEND_CID */
#define CMD12 (12)		   /* STOP_TRANSMISSION */
#define ACMD13 (0x80 + 13) /* SD_STATUS (SDC) */
#define CMD16 (16)		   /* SET_BLOCKLEN */
#define CMD17 (17)		   /* READ_SINGLE_BLOCK */
#define CMD18 (18)		   /* READ_MULTIPLE_BLOCK */
#define CMD23 (23)		   /* SET_BLOCK_COUNT (MMC) */
#define ACMD23 (0x80 + 23) /* SET_WR_BLK_ERASE_COUNT (SDC) */
#define CMD24 (24)		   /* WRITE_BLOCK */
#define CMD25 (25)		   /* WRITE_MULTIPLE_BLOCK */
#define CMD32 (32)		   /* ERASE_ER_BLK_START */
#define CMD33 (33)		   /* ERASE_ER_BLK_END */
#define CMD38 (38)		   /* ERASE */
#define CMD55 (55)		   /* APP_CMD */
#define CMD58 (58)		   /* READ_OCR */


typedef struct {
    spi_inst_t *spiPort;
    bool spiInit;
    uint csPin;
    BYTE cardType;
    uint16_t sectSize;
#ifdef __SPI_SDMMC_DMA
    uint read_dma_ch;
    uint write_dma_ch;
    dma_channel_config dma_rc;
    dma_channel_config dma_wc;
    bool dmaInit;
#endif
    DRESULT Stat;
}sdmmc_data_t;


//BYTE sdmmc_init(sdmmc_data_t *sdmmc);
DSTATUS sdmmc_disk_initialize(sdmmc_data_t *sdmmc);
DSTATUS sdmmc_disk_status(sdmmc_data_t *sdmmc);
DSTATUS sdmmc_disk_read(BYTE *buff, LBA_t sector,	UINT count, sdmmc_data_t *sdmmc); 
DSTATUS sdmmc_disk_write(const BYTE *buff, LBA_t sector, UINT count, sdmmc_data_t *sdmmc);
DSTATUS sdmmc_disk_ioctl ( BYTE cmd, void *buff, sdmmc_data_t *sdmmc);

//static 
int sdmmc_read_datablock (BYTE *buff, UINT btr, sdmmc_data_t *sdmmc);
//static 
int sdmmc_write_datablock (const BYTE *buff, BYTE token, sdmmc_data_t *sdmmc);
//static 
BYTE sdmmc_send_cmd(BYTE cmd,  DWORD arg, sdmmc_data_t *sdmmc);

/* MMC card type flags (MMC_GET_TYPE) */
#define CT_MMC3		0x01		/* MMC ver 3 */
#define CT_MMC4		0x02		/* MMC ver 4+ */
#define CT_MMC		0x03		/* MMC */
#define CT_SDC1		0x02		/* SDC ver 1 */
#define CT_SDC2		0x04		/* SDC ver 2+ */
#define CT_SDC		0x0C		/* SDC */
#define CT_BLOCK	0x10		/* Block addressing */
#endif 
  • 主程式碼:
#include <stdio.h>
#include "pico/stdlib.h"
#include "hardware/spi.h"
#include "hardware/dma.h"
#include "stdlib.h"
#include "stdio.h"
#include "ff.h"
#include "diskio.h"
#include "string.h"
#include "spi_sdmmc.h"

#include "inttypes.h"

extern sdmmc_data_t *pSDMMC;
void test_sdmmc_raw_rw(uint8_t *buff) {
    if (pSDMMC == NULL){
       pSDMMC = (sdmmc_data_t*)malloc(sizeof(sdmmc_data_t));
        pSDMMC->csPin = SDMMC_PIN_CS;
        pSDMMC->spiPort = SDMMC_SPI_PORT;
        pSDMMC->spiInit=false;
        pSDMMC->sectSize=512;
#ifdef __SPI_SDMMC_DMA
        pSDMMC->dmaInit=false;
#endif
        printf("sdmmc_init:%0x\n", sdmmc_disk_initialize(pSDMMC));
    }
    printf("-------------------------------------------------------\n");
    printf("Being testing...\n");
    // WRITE SINGLE B:OCL
    printf("\n===============\n");
    printf("Directly write a single block of data to the SDMMC card, the address is 51200. \n");
#ifdef __SPI_SDMMC_DMA
    printf("with DMA:  ");
#endif
    printf("data is written:\n");
    printf("\n--------------");
    for (int i = 0; i < 512; i++){
        if (i % 80==0) printf("\n");
        printf("%c", buff[i]);
    } 
    if ((sdmmc_send_cmd(CMD24, 51200, pSDMMC) == 0)) {
                sdmmc_write_datablock(buff, 0xFE, pSDMMC);
    }
    printf("\n===============\n");
    memset(buff, 0xFF, 512);
    printf("clear buffer\n");
    // READ_SINGLE_BLOCK 
    printf("\n===============\n");
    printf("Directly read a single block of data from  the SDMMC card at address is 51200\n");
#ifdef __SPI_SDMMC_DMA
    printf("with DMA:  ");
#endif
    printf("data is read:\n");
    printf("\n--------------");
    if ((sdmmc_send_cmd(CMD17, 51200, pSDMMC) == 0)) {
            sdmmc_read_datablock(buff, 512, pSDMMC);
            for (int i = 0; i < 512; i++){
                if (i % 80==0) printf("\n");
                printf("%c", buff[i]);
            }        
                
    }
    printf("\n");

}

void test_sdmmc_flash_rw_fatfs(uint8_t *buff) {
    FRESULT res;
    FATFS fs0, fs1;
    FIL fil0, fil1;
    
    uint br;
    uint loop_count=100;

    absolute_time_t time1, time2;
   
   printf("-------------------------------------------------------\n");
    printf("Begin testing(read data from sdmmc and write to flash memory device)...\n");
    res = f_mount(&fs0, SDMMC_PATH, 1);
    if (res != FR_OK) {
        printf(" mount error\n"); return;
    }
    printf("mount SDMMC_PATH ok\n");

    res = f_mount(&fs1, W25Q_PATH, 1);
    if (res != FR_OK) {
        printf(" mount error\n"); return;
    }
    printf("mount W25Q_PATH ok\n");
 
    printf("=================\n");
#ifdef __SPI_SDMMC_DMA
    printf("With DMA:  ");
#else 
    printf("Without DMA:  ");
#endif 
    printf(" write 0.8MB data to SD/MMC card.\n");
    time1=get_absolute_time();
    res= f_open(&fil0, SDMMC_PATH"/tfile1.txt", FA_CREATE_ALWAYS|FA_WRITE);
    if (res != FR_OK) {
        printf("open write error\n");
        return;
    }
    for (int i = 0; i < loop_count; i++)
        res = f_write(&fil0, buff, 8192, &br);
    f_close(&fil0);
    time2=get_absolute_time();
    printf("\nwrite total Time:%"PRId64"(us)\n\n", absolute_time_diff_us(time1,time2));

printf("=================\n");
#ifdef __SPI_SDMMC_DMA
    printf("With DMA:  ");
#else 
    printf("Without DMA:  ");
#endif 
    printf(" read 0.8MB data from SD/MMC card and write to Flash memory device.\n");
    time2=get_absolute_time();
    res = f_open(&fil1, W25Q_PATH"/tfile1.txt", FA_CREATE_ALWAYS|FA_WRITE);
    res = f_open(&fil0, SDMMC_PATH"/tfile1.txt",FA_READ );
    if (res != FR_OK) {
        printf("error\n");
        return;
    }
    for (int i = 0; i < loop_count; i++)
        f_read(&fil0, buff, 8192, &br);
        f_write(&fil1, buff, 8192, &br);
    f_close(&fil0);
    f_close(&fil1);
    time1=get_absolute_time();
    printf("\ntotal Time:%"PRId64"(us)\n\n", absolute_time_diff_us(time2,time1));

    f_unmount(SDMMC_PATH);
    f_unmount(W25Q_PATH);
    
}
void test_sdmmc_rw_with_fatfs(uint8_t *buff) {
    FRESULT res;
    FATFS fs0;
    FIL fil0;    
    uint br;
    uint loop_count=4096;

    res = f_mount(&fs0, SDMMC_PATH, 1);
    if (res != FR_OK) {
        printf(" mount error\n"); return;
    }
    printf("-------------------------------------------------------\n");
    printf("Begin testing(SD/MMC card read/write with filesystem support)...\n");
    printf("mount SDMMC_PATH ok\n");

    absolute_time_t time1, time2;

    printf("\n==================\n");
#ifdef __SPI_SDMMC_DMA
    printf("With DMA:  ");
#else 
    printf("Without DMA:  ");
#endif 
    printf("Write 32MB data to sd/mmc card.\n");

    time1=get_absolute_time();
    res= f_open(&fil0, SDMMC_PATH"/testfile.txt", FA_CREATE_ALWAYS|FA_WRITE);
    if (res != FR_OK) {
        printf("open write error\n");
        return;
    }
    
    for (int i = 0; i < loop_count; i++) {
        if (i%10==0) {
            printf(".");
            gpio_put(PICO_DEFAULT_LED_PIN, !gpio_get(PICO_DEFAULT_LED_PIN));
        }
        res = f_write(&fil0, buff, 8192, &br);
    }
        
    f_close(&fil0);

    time2=get_absolute_time();
    printf("\nwrite total Time:%"PRId64"(us)\n", absolute_time_diff_us(time1,time2));

    printf("\n==================\n");
#ifdef __SPI_SDMMC_DMA
    printf("With DMA:  ");
#else 
    printf("Without DMA:  ");
#endif 
    printf("Read 32MB data from sd/mmc card.\n");
    res = f_open(&fil0, SDMMC_PATH"/testfile.txt",FA_READ );
    if (res != FR_OK) {
        printf("error\n");
        return;
    }
    for (int i = 0; i < loop_count; i++) {
        if (i%10==0) {
            printf(".");
            gpio_put(PICO_DEFAULT_LED_PIN, !gpio_get(PICO_DEFAULT_LED_PIN));
        } 
        
        f_read(&fil0, buff, 8192, &br);
    }
        

f_close(&fil0);

    time1=get_absolute_time();
    printf("\nread total Time:%"PRId64"(us)\n\n", absolute_time_diff_us(time2,time1));


    f_unmount(SDMMC_PATH);

    
}

void test_flash_rw_with_fatfs(uint8_t *buff) {
    FRESULT res;
    FATFS fs0;
    FIL fil0;    
    uint br;
    uint loop_count=256;

    res = f_mount(&fs0, W25Q_PATH, 1);
    if (res != FR_OK) {
        printf(" mount error\n"); return;
    }
    printf("-------------------------------------------------------\n");
    printf("Begin testing(Flash memory device read/write with filesystem support)...\n");
    printf("mount W25Q_PATH ok\n");

    absolute_time_t time1, time2;

    printf("\n==================\n");

    printf("Write 2MB data to Flash Memory device.\n");

    time1=get_absolute_time();
    res= f_open(&fil0, W25Q_PATH"/tfile2.txt", FA_CREATE_ALWAYS|FA_WRITE);
    if (res != FR_OK) {
        printf("open write error\n");
        return;
    }
    
    for (int i = 0; i < loop_count; i++) {
        printf(".");
        gpio_put(PICO_DEFAULT_LED_PIN, !gpio_get(PICO_DEFAULT_LED_PIN));
        res = f_write(&fil0, buff, 8192, &br);
    }
    f_close(&fil0);

    time2=get_absolute_time();
    printf("\nwrite total Time:%"PRId64"(us)\n", absolute_time_diff_us(time1,time2));

    printf("\n==================\n");

    printf("Read 2MB data from  Flash Memory device.\n");
    res = f_open(&fil0, W25Q_PATH"/tfile2.txt",FA_READ );
    if (res != FR_OK) {
        printf("error\n");
        return;
    }
    for (int i = 0; i < loop_count; i++) {
        printf(".");
        gpio_put(PICO_DEFAULT_LED_PIN, !gpio_get(PICO_DEFAULT_LED_PIN));
        f_read(&fil0, buff, 8192, &br);
    }
        

    f_close(&fil0);

    time1=get_absolute_time();
    printf("\nread total Time:%"PRId64"(us)\n\n", absolute_time_diff_us(time2,time1));


    f_unmount(W25Q_PATH);

    
}
int main()
{
    stdio_init_all();
    uint8_t buff[8192];
    uint8_t r;
    for (int i=0; i< 8192; i++) {
        r = rand()%126;
        if (r < 32) r+=32;
        buff[i] = r;
    }
    gpio_init(PICO_DEFAULT_LED_PIN);
    gpio_set_dir(PICO_DEFAULT_LED_PIN, true);

    //test_sdmmc_raw_rw(buff);

    test_sdmmc_rw_with_fatfs(buff);
    test_sdmmc_flash_rw_fatfs(buff);
    test_flash_rw_with_fatfs(buff);
    

    gpio_put(PICO_DEFAULT_LED_PIN, 0);

    
//puts("Hello, world!");

    return 0;
}

2022年11月24日 星期四

[Raspberry Pi Pico (c-sdk)] Storage: Ep 2. Multi external flash memory devices with FatFs filesystem

本文章介紹在Raspberry Pi Pico環境使用兩個以上外加的Flash memory device,並使用FatFs 檔案系統格式化為Fat。

一、使用元件:

  1. Raspberry Pi Pico -- 1
  2. Winbond W25Q128FV 16MB -- 2


二、接線:

兩個Winbond W25Q128FV Flash memory 都接在SPI 0,第一個Flash 使用 CS Pin 17,第二個使用CS Pin 20。

三、流程說明:


  • 修改glue.c function針對每個Volume(Logical driver)呼叫個別的disk_status, disk_initialize, disk_read, disk_write, disk_ioctl。

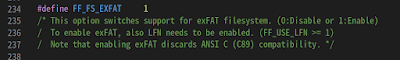
  • 修改ffconf.h中的:

#define FF_VOLUMES 4
/* Number of volumes (logical drives) to be used. (1-10) */
設定要同時使用的Volumes數

#define FF_FS_LOCK 5
/* The option FF_FS_LOCK switches file lock function to control duplicated file open
/  and illegal operation to open objects. This option must be 0 when FF_FS_READONLY
/  is 1.
/
/  0:  Disable file lock function. To avoid volume corruption, application program
/      should avoid illegal open, remove and rename to the open objects.
/  >0: Enable file lock function. The value defines how many files/sub-directories
/      can be opened simultaneously under file lock control. Note that the file
/      lock control is independent of re-entrancy. */
設定要同時開啟的檔案數

  • 測試流程
  1. 個別執行f_mkfs將每個volume(flash device)格式化。
  2. 建立8KB亂數產生的測試資料。
  3. 在volume 0 建立test_p01.txt, test_p02.txt與test.txt三個檔案。在volume 1建立pat1_p11.txt, pat1_p12.txt與test.txt。
  4. 針對volume 0 與volume 1的test.txt寫入不同資料,再讀取以便驗證為確實在不同的volume上。
  5. 分別列出volume 0 與 volume 1的檔案名稱。
  • 測試結果


四、成果影片:


五、程式碼:
  • W25Q.c
#include "stdio.h"
#include "stdlib.h"
#include "W25Q.h"

#include "FatFs/ff.h"
#include "FatFs/ffconf.h"

uint8_t rxbuf[10];
uint8_t txbuf[10];

static bool spi_lock=false;
static bool w25q_spi_init_flag=false;

/*=================*/

const uint8_t i_uniqueid=0x4b;
const uint8_t i_page_program=0x02;
const uint8_t i_read_data=0x03;
const uint8_t i_fast_read_data=0x0b;
const uint8_t i_write_disable=0x04;
const uint8_t i_read_status_r1=0x05;
const uint8_t i_read_status_r2=0x35;
const uint8_t i_read_status_r3=0x15;
const uint8_t i_write_status_r1=0x01;
const uint8_t i_write_status_r2=0x31;
const uint8_t i_write_status_r3=0x11;
const uint8_t i_sector_erase=0x20;
const uint8_t i_block_erase_32k=0x52;
const uint8_t i_block_erase_64k=0xd8;
const uint8_t i_write_enable=0x06;
const uint8_t i_erase_chip=0xc7;

const uint8_t i_device_id=0x90;
const uint8_t i_JEDEC_ID=0x9f;

void w25q_spi_port_init() {
    gpio_set_dir(PIN_CS_0, GPIO_OUT);
    gpio_set_dir(PIN_CS_1, GPIO_OUT);

    gpio_put(PIN_CS_0, 1);
    gpio_put(PIN_CS_1, 1);
    
    gpio_set_function(PIN_MISO, GPIO_FUNC_SPI);
    gpio_set_function(PIN_SCK,  GPIO_FUNC_SPI);
    gpio_set_function(PIN_MOSI, GPIO_FUNC_SPI);
    gpio_set_function(PIN_CS_0,   GPIO_FUNC_SIO);
    gpio_set_function(PIN_CS_1,   GPIO_FUNC_SIO);

    spi_init(SPI_PORT, 5000*1000);
    w25q_spi_init_flag=true;
}

void w25q_spi_cs_low(w25q_data_t *w25q) {
    gpio_put(w25q->cs_pin,0);
}
void w25q_spi_cs_high(w25q_data_t *w25q){
    gpio_put(w25q->cs_pin,1);
}
void w25q_send_cmd_read(uint8_t cmd, uint32_t address, uint8_t *buf, uint32_t len, bool is_fast, w25q_data_t *w25q) {
    uint8_t addr[4];
    int addr_len=3;
    addr[3] = 0x00;
    if (is_fast) addr_len=4;
    addr[0] = (address & 0x00ff0000) >> 16;
    addr[1] = (address & 0x0000ff00) >> 8;
    addr[2] = (address & 0x000000ff);
    w25q_spi_cs_low(w25q);
    spi_write_blocking(w25q->spi, &cmd, 1);
    spi_write_blocking(w25q->spi, addr, addr_len);
    spi_read_blocking(w25q->spi, 0x00, buf, len);
    w25q_spi_cs_high(w25q);
}

void w25q_send_cmd_write(uint8_t cmd, uint32_t address, uint8_t *buf, uint32_t len, w25q_data_t *w25q) {
    uint8_t addr[3];
    
    addr[0] = (address & 0x00ff0000) >> 16;
    addr[1] = (address & 0x0000ff00) >> 8;
    addr[2] = (address & 0x000000ff);
    w25q_write_enable(w25q);
    w25q_spi_cs_low(w25q);
    spi_write_blocking(w25q->spi, &cmd, 1);
    spi_write_blocking(w25q->spi, addr, 3);
    spi_write_blocking(w25q->spi, buf, len);
    w25q_spi_cs_high(w25q);

}

void w25q_send_cmd_addr(uint8_t cmd, uint32_t address, w25q_data_t *w25q) {
    uint8_t addr[3];
    addr[0] = (address & 0x00ff0000) >> 16;
    addr[1] = (address & 0x0000ff00) >> 8;
    addr[2] = (address & 0x000000ff);
    w25q_spi_cs_low(w25q);
    spi_write_blocking(w25q->spi, &cmd, 1);
    spi_write_blocking(w25q->spi, addr, 3);
    w25q_spi_cs_high(w25q);
}

void w25q_send_cmd(uint8_t cmd, uint8_t *buf, uint32_t len, w25q_data_t *w25q) {
    w25q_spi_cs_low(w25q);
    spi_write_blocking(w25q->spi, &cmd, 1);
    spi_read_blocking(w25q->spi, 0x00, buf, len);
    w25q_spi_cs_high(w25q);
}

void w25q_send_simple_cmd(uint8_t cmd, w25q_data_t *w25q) {
    w25q_spi_cs_low(w25q);
    spi_write_blocking(w25q->spi, &cmd, 1);
    w25q_spi_cs_high(w25q);
}

void w25q_write_enable(w25q_data_t *w25q) {
    w25q_send_simple_cmd(i_write_enable, w25q);
    sleep_ms(1);
}
void w25q_write_disable(w25q_data_t *w25q) {
    w25q_send_simple_cmd(i_write_disable, w25q);
    sleep_ms(1);
}

/*==================*/
bool w25q_spi_init(spi_inst_t *spi, uint cs_pin, w25q_data_t *w25q) {
    w25q->spi = spi;
    w25q->cs_pin = cs_pin;
    
    if (!w25q_spi_init_flag) w25q_spi_port_init();

    w25q_get_JEDEC_ID(w25q);
    w25q->lock = 1;
	sleep_ms(100);
	switch (w25q->jedec_id & 0x000000FF)
	{
	    case 0x20: // 	w25q512
		    w25q->blockCount = 1024;
		break;
	    case 0x19: // 	w25q256
		    w25q->blockCount = 512;
		break;
	    case 0x18: // 	w25q128
		    w25q->blockCount = 256;
		break;
	    case 0x17: //	w25q64
		    w25q->blockCount = 128;
		break;
	    case 0x16: //	w25q32
		    w25q->blockCount = 64;
		break;
        case 0x15: //	w25q16
            w25q->blockCount = 32;
            break;
        case 0x14: //	w25q80
            w25q->blockCount = 16;
            break;
        case 0x13: //	w25q40
            w25q->blockCount = 8;
        case 0x12: //	w25q20
            w25q->blockCount = 4;
            break;
        case 0x11: //	w25q10
            w25q->blockCount = 2;
            break;
        default:
            w25q->lock = 0;
            return false;
    }
	w25q->pageSize = 256;
	w25q->sectorSize = 0x1000;
	w25q->sectorCount = w25q->blockCount * 16;
	w25q->pageCount = (w25q->sectorCount * w25q->sectorSize) / w25q->pageSize;
	w25q->blockSize = w25q->sectorSize * 16;
	w25q->capacityKB = (w25q->sectorCount * w25q->sectorSize) / 1024;
	w25q_get_uid(w25q);
    w25q_read_status_register_1(w25q);
    w25q_read_status_register_2(w25q);
    w25q_read_status_register_3(w25q);
	w25q->lock = 0;
	return true;
}


void w25q_read_status_register_1(w25q_data_t *w25q){
    w25q_send_cmd(i_read_status_r1, &w25q->statusRegister1, 1, w25q);
}
void w25q_read_status_register_2(w25q_data_t *w25q){
    w25q_send_cmd(i_read_status_r2, &w25q->statusRegister2, 1, w25q);
}
void w25q_read_status_register_3(w25q_data_t *w25q){
    w25q_send_cmd(i_read_status_r3, &w25q->statusRegister3, 1, w25q);
}

void w25q_write_status_register_1(w25q_data_t *w25q){
    w25q_send_cmd(i_write_status_r1, &w25q->statusRegister1, 1, w25q);
}
void w25q_write_status_register_2(w25q_data_t *w25q){
    w25q_send_cmd(i_write_status_r2, &w25q->statusRegister2, 1, w25q);
}
void w25q_write_status_register_3(w25q_data_t *w25q){
    w25q_send_cmd(i_write_status_r3, &w25q->statusRegister3, 1, w25q);
}

void w25q_wait_for_write_end(w25q_data_t *w25q)
{
	sleep_ms(1);
	w25q_spi_cs_low(w25q);
	spi_write_blocking(w25q->spi, &i_read_status_r1,1);
	do
	{
		spi_read_blocking(w25q->spi, 0x00, &w25q->statusRegister1,1);
		sleep_ms(1);
	} while ((w25q->statusRegister1 & 0x01) == 0x01);
	w25q_spi_cs_high(w25q);
}

void w25q_erase_chip(w25q_data_t *w25q) {
    while (w25q->lock) sleep_ms(1);
    w25q->lock=1;
    w25q_write_enable(w25q);
    w25q_send_simple_cmd(i_erase_chip, w25q);
    w25q_wait_for_write_end(w25q);
    sleep_ms(10);
    w25q->lock=0;
}

void w25q_page_program(uint32_t page_addr, uint16_t offset, uint8_t *buf, uint32_t len, w25q_data_t *w25q) {
    while (w25q->lock) sleep_ms(1);
    w25q->lock=1;
    if (offset + len > w25q->pageSize) {
        len = w25q->pageSize - offset;
    }
    page_addr = (page_addr * w25q->pageSize) + offset;
    w25q_wait_for_write_end(w25q);
    w25q_write_enable(w25q);
    w25q_send_cmd_write(i_page_program, page_addr, buf, len, w25q);
    w25q_wait_for_write_end(w25q);
    sleep_ms(1);
    w25q->lock=0;
}
/*===========================*/
uint32_t w25_page_to_sector_address(uint32_t pageAddress, w25q_data_t *w25q)
{
	return ((pageAddress * w25q->pageSize) / w25q->sectorSize);
}
uint32_t w25q_page_to_block_address(uint32_t pageAddress, w25q_data_t *w25q)
{
	return ((pageAddress * w25q->pageSize) / w25q->blockSize);
}
uint32_t w25q_data_sector_to_block_address(uint32_t sectorAddress, w25q_data_t *w25q)
{
	return ((sectorAddress * w25q->sectorSize) / w25q->blockSize);
}
uint32_t w25q_sector_to_page_address(uint32_t sectorAddress, w25q_data_t *w25q)
{
	return (sectorAddress * w25q->sectorSize) / w25q->pageSize;
}
uint32_t w25q_block_to_page_address(uint32_t blockAddress, w25q_data_t *w25q)
{
	return (blockAddress * w25q->blockSize) / w25q->pageSize;
}
/*============================*/

void w25q_write_sector(uint32_t sect_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q) {
	if (offset >= w25q->sectorSize) return;
    if (offset + len  > w25q->sectorSize) 
		len = w25q->sectorSize - offset;
	uint32_t startPage;
	int32_t bytesToWrite;
	uint32_t localOffset;


    startPage = w25q_sector_to_page_address(sect_addr, w25q) + (offset / w25q->pageSize);
	localOffset = offset % w25q->pageSize;
    bytesToWrite = len;

	do
	{
        w25q_page_program(startPage, localOffset, buf, bytesToWrite, w25q);
		startPage++;
		bytesToWrite -= w25q->pageSize - localOffset;
		buf += w25q->pageSize - localOffset;
		localOffset = 0;
	} while (bytesToWrite > 0);

}

void w25q_write_block_64k(uint32_t blk_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q) {
	if ((len > w25q->blockSize) || (len == 0))
		len = w25q->blockSize;
	if (offset >= w25q->blockSize)
		return;
	uint32_t startPage;
	int32_t bytesToWrite;
	uint32_t localOffset;
	if ((offset + len) > w25q->blockSize)
		bytesToWrite = w25q->blockSize - offset;
	else
		bytesToWrite = len;
	startPage = w25q_block_to_page_address(blk_addr, w25q) + (offset / w25q->pageSize);
	localOffset = offset % w25q->pageSize;
	do
	{
		w25q_page_program(startPage, localOffset, buf, len, w25q);
		startPage++;
		bytesToWrite -= w25q->pageSize - localOffset;
		buf += w25q->pageSize - localOffset;
		localOffset = 0;
	} while (bytesToWrite > 0);
   
}

void w25q_read_bytes(uint32_t address, uint8_t *buf, uint32_t len, w25q_data_t *w25q) {
	while (w25q->lock == 1) sleep_ms(1);
	w25q->lock = 1;
    w25q_send_cmd_read(i_fast_read_data, address, buf, len, true, w25q);
	sleep_ms(1);
	w25q->lock = 0;
}

void w25q_read_page(uint32_t page_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q) {
	while (w25q->lock == 1) sleep_ms(1);
	w25q->lock = 1;
    if (offset >= w25q->pageSize) return;
	if ((offset + len) >= w25q->pageSize)
		len = w25q->pageSize - offset;
	page_addr = page_addr * w25q->pageSize + offset;
    w25q_send_cmd_read(i_fast_read_data, page_addr, buf, len, true, w25q);
	
	sleep_ms(1);
	w25q->lock = 0;
}

void w25q_read_sector(uint32_t sect_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q) {
	if (offset >= w25q->sectorSize) return;
    if (offset + len > w25q->sectorSize)
		len = w25q->sectorSize - offset;
	uint32_t startPage;
	int32_t bytesToRead;
	uint32_t localOffset;
    bytesToRead = len;
	
    startPage = w25q_sector_to_page_address(sect_addr, w25q) + (offset / w25q->pageSize);
	localOffset = offset % w25q->pageSize;

	do
	{
		w25q_read_page(startPage, localOffset, buf, bytesToRead, w25q);
		startPage++;
		bytesToRead -= w25q->pageSize - localOffset;
		buf += w25q->pageSize - localOffset;
		localOffset = 0;
	} while (bytesToRead > 0);

}
void w25q_read_block(uint32_t blk_addr, uint32_t offset, uint8_t *buf, uint32_t len, w25q_data_t *w25q) {
	if (offset+len > w25q->blockSize)
		len = w25q->blockSize-offset;

	uint32_t startPage;
	int32_t bytesToRead;
	uint32_t localOffset;
    bytesToRead = len;

	startPage = w25q_block_to_page_address(blk_addr, w25q) + (offset / w25q->pageSize);
	localOffset = offset % w25q->pageSize;
	do
	{
		w25q_read_page(startPage, localOffset, buf, bytesToRead, w25q);
		startPage++;
		bytesToRead -= w25q->pageSize - localOffset;
		buf += w25q->pageSize - localOffset;
		localOffset = 0;
	} while (bytesToRead > 0);

}


void w25q_sector_erase(uint32_t sect_addr, w25q_data_t *w25q) {
    while(w25q->lock) sleep_ms(1);
    w25q->lock=1;
    sect_addr = sect_addr * w25q->sectorSize;
    w25q_wait_for_write_end(w25q);
    w25q_write_enable(w25q);
    w25q_send_cmd_addr(i_sector_erase, sect_addr, w25q);
    w25q_wait_for_write_end(w25q);
    sleep_ms(1);
    w25q->lock=0;
}
void w25q_block_erase_32k(uint32_t blk_addr, w25q_data_t *w25q) {
    while(w25q->lock) sleep_ms(1);
    w25q->lock=1;
    blk_addr = blk_addr * w25q->sectorSize * 8;
    w25q_wait_for_write_end(w25q);
    w25q_write_enable(w25q);
    w25q_send_cmd_addr(i_block_erase_32k, blk_addr, w25q);
    w25q_wait_for_write_end(w25q);
    sleep_ms(1);
    w25q->lock=0;
}
void w25q_block_erase_64k(uint32_t blk_addr, w25q_data_t *w25q) {
    while(w25q->lock) sleep_ms(1);
    w25q->lock=1;
    blk_addr = blk_addr * w25q->sectorSize * 16;
    w25q_wait_for_write_end(w25q);
    w25q_write_enable(w25q);
    w25q_send_cmd_addr(i_block_erase_64k, blk_addr, w25q);
    w25q_wait_for_write_end(w25q);
    sleep_ms(1);
    w25q->lock=0;
}
void w25q_get_manufacter_device_id(uint8_t *mid, w25q_data_t *w25q){
    assert(w25q->spi);
    w25q_send_cmd_read(i_device_id, 0x000000, mid, 2, false, w25q);
}


void w25q_get_JEDEC_ID(w25q_data_t *w25q) {
    uint8_t temp[3];
    w25q_send_cmd(i_JEDEC_ID, temp, 3, w25q);
    w25q->jedec_id = ((uint32_t)temp[0] << 16) | ((uint32_t)temp[1] << 8) | (uint32_t)temp[2];
}
void w25q_get_uid(w25q_data_t *w25q) {
    assert(w25q->spi);
    txbuf[0]= 0x4b;
    txbuf[1] = 0x00; txbuf[2] = 0x00; txbuf[3] = 0x00;txbuf[4]=0x00;
    w25q_spi_cs_low(w25q);
    spi_write_blocking(w25q->spi, txbuf, 5);
    spi_read_blocking(w25q->spi, 0x00, w25q->uuid, 8);
    w25q_spi_cs_high(w25q);
}
  • w25Q.h
#ifndef W25Q_H
#define W25Q_H
#include "stdio.h"
#include "stdlib.h"
#include "pico/stdlib.h"
#include "hardware/spi.h"


#define SPI_PORT spi0
#define PIN_MISO 16
#define PIN_SCK  18
#define PIN_MOSI 19

#define PIN_CS_0 17
#define PIN_CS_1 20   

typedef struct{
    spi_inst_t *spi;
    uint        cs_pin;
    uint8_t     uuid[8];
    uint32_t    jedec_id;
    uint32_t    blockCount;
    uint32_t    pageCount;
    uint32_t    sectorCount;
    uint16_t    pageSize;
    uint32_t    sectorSize;
    uint32_t    blockSize;
    uint8_t     statusRegister1;
    uint8_t     statusRegister2;
    uint8_t     statusRegister3;
    uint32_t    capacityKB;
    uint8_t     lock;
    uint8_t     Stat;
}w25q_data_t;


bool w25q_spi_init(spi_inst_t *spi, uint cs_pin, w25q_data_t *w25q);
void w25q_get_manufacter_device_id(uint8_t *mid, w25q_data_t *w25q);
void w25q_get_JEDEC_ID(w25q_data_t *w25q);
void w25q_erase_chip(w25q_data_t *w25q);
void w25q_page_program(uint32_t page_addr, uint16_t offset, uint8_t *buf, uint32_t len, w25q_data_t *w25q);
void w25q_write_sector(uint32_t sect_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q);
void w25q_write_block_64k(uint32_t blk_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q);
void w25q_read_bytes(uint32_t address, uint8_t *buf, uint32_t len, w25q_data_t *w25q);
void w25q_read_page(uint32_t page_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q);
void w25q_read_sector(uint32_t sect_addr, uint32_t offset, uint8_t *buf,  uint32_t len, w25q_data_t *w25q);
void w25q_read_block(uint32_t blk_addr, uint32_t offset, uint8_t *buf, uint32_t len, w25q_data_t *w25q);
//void w25q_read_data(uint32_t address, uint8_t *buf, uint32_t len);
//void w25q_fast_read_data(uint32_t address, uint8_t *buf, uint32_t len);
void w25q_read_status_register_1(w25q_data_t *w25q);
void w25q_read_status_register_2(w25q_data_t *w25q);
void w25q_read_status_register_3(w25q_data_t *w25q);
void w25q_write_status_register_1(w25q_data_t *w25q);
void w25q_write_status_register_2(w25q_data_t *w25q);
void w25q_write_status_register_3(w25q_data_t *w25q);
void w25q_sector_erase(uint32_t sect_addr, w25q_data_t *w25q);
void w25q_block_erase_32k(uint32_t blk_addr,w25q_data_t *w25q);
void w25q_block_erase_64k(uint32_t blk_addr, w25q_data_t *w25q);
void w25q_get_uid(w25q_data_t *w25q);
void w25q_write_enable(w25q_data_t *w25q);
void w25q_write_diable(w25q_data_t *w25q);

#endif
  • glue.c
#include "stdio.h"
#include "ff.h"			/* Obtains integer types */
#include "diskio.h"		/* Declarations of disk functions */
#include "W25Q.h"
#include "hardware/rtc.h"
#include "pico/util/datetime.h"
#include "stdlib.h"

#define SPI_FLASH_0	0
#define SPI_FLASH_1 1

w25q_data_t *w25q_spi_cs0=NULL;
w25q_data_t *w25q_spi_cs1=NULL;

DSTATUS Stat = STA_NOINIT;

/*-----------------------------------------------------------------------*/
/* Get Drive Status                                                      */
/*-----------------------------------------------------------------------*/

DSTATUS disk_status (
	BYTE pdrv		/* Physical drive nmuber to identify the drive */
)
{
	DSTATUS stat;
	stat = STA_NOINIT;
	if (pdrv == SPI_FLASH_0 && w25q_spi_cs0) {
		stat = w25q_spi_cs0->Stat;
	} 
	if (pdrv == SPI_FLASH_1 && w25q_spi_cs1) {
		stat = w25q_spi_cs0->Stat;
	}
	return stat;
}

/*-----------------------------------------------------------------------*/
/* Inidialize a Drive                                                    */
/*-----------------------------------------------------------------------*/

DSTATUS disk_initialize (
	BYTE pdrv				/* Physical drive nmuber to identify the drive */
)
{
	DSTATUS stat;
	stat=STA_NOINIT;
	switch (pdrv) {
		case SPI_FLASH_0:
		if (w25q_spi_cs0 == NULL) w25q_spi_cs0 = (w25q_data_t*)malloc(sizeof(w25q_data_t));
		if (w25q_spi_init(SPI_PORT, PIN_CS_0, w25q_spi_cs0)) {
			w25q_spi_cs0->Stat = RES_OK;
			stat = w25q_spi_cs0->Stat;
		}
		break;
		case SPI_FLASH_1:
		if (w25q_spi_cs1 == NULL) w25q_spi_cs1 = (w25q_data_t*)malloc(sizeof(w25q_data_t));
		if (w25q_spi_init(SPI_PORT, PIN_CS_1, w25q_spi_cs1)) {
			w25q_spi_cs1->Stat = RES_OK;
			stat = w25q_spi_cs1->Stat;
		}
		break;
	}
 	return stat;
}

/*-----------------------------------------------------------------------*/
/* Read Sector(s)                                                        */
/*-----------------------------------------------------------------------*/

DRESULT disk_read (
	BYTE pdrv,		/* Physical drive nmuber to identify the drive */
	BYTE *buff,		/* Data buffer to store read data */
	LBA_t sector,	/* Start sector in LBA */
	UINT count		/* Number of sectors to read */
)
{
	DRESULT res;

	switch (pdrv) {
		case SPI_FLASH_0:
		if (w25q_spi_cs0->Stat & STA_NOINIT) return RES_NOTRDY;
		w25q_read_sector(sector, 0, buff, count*w25q_spi_cs0->sectorSize, w25q_spi_cs0);
		break;
		case SPI_FLASH_1:
		if (w25q_spi_cs1->Stat & STA_NOINIT) return RES_NOTRDY;
		w25q_read_sector(sector, 0, buff, count*w25q_spi_cs1->sectorSize, w25q_spi_cs1);
		break;
	}

	return RES_OK;
}

/*-----------------------------------------------------------------------*/
/* Write Sector(s)                                                       */
/*-----------------------------------------------------------------------*/

#if FF_FS_READONLY == 0

DRESULT disk_write (
	BYTE pdrv,			/* Physical drive nmuber to identify the drive */
	const BYTE *buff,	/* Data to be written */
	LBA_t sector,		/* Start sector in LBA */
	UINT count			/* Number of sectors to write */
)
{
	BYTE *tbuf=(BYTE*)buff;
	w25q_data_t * tmp_w25q=NULL;

	switch (pdrv) {
		case SPI_FLASH_0:
		if (w25q_spi_cs0 == NULL) return RES_NOTRDY;
		tmp_w25q = w25q_spi_cs0;
		break;
		case SPI_FLASH_1:
		if (w25q_spi_cs1 == NULL) return RES_NOTRDY;
		tmp_w25q = w25q_spi_cs1;
		break;
	}
	if (pdrv == SPI_FLASH_0 || pdrv == SPI_FLASH_1) {
		while(count > 1)
		{
			w25q_sector_erase(sector, tmp_w25q);
			w25q_write_sector(sector, 0, tbuf, tmp_w25q->sectorSize, tmp_w25q);
			count--;
			tbuf += tmp_w25q->sectorSize;
			sector++;
		}
		if (count == 1)
		{
			w25q_sector_erase(sector, tmp_w25q);
			w25q_write_sector(sector, 0, tbuf, tmp_w25q->sectorSize, tmp_w25q);
			count--;
		}
	}
	return count ? RES_ERROR : RES_OK;
}

#endif

/*-----------------------------------------------------------------------*/
/* Miscellaneous Functions                                               */
/*-----------------------------------------------------------------------*/

DRESULT disk_ioctl (
	BYTE pdrv,		/* Physical drive nmuber (0..) */
	BYTE cmd,		/* Control code */
	void *buff		/* Buffer to send/receive control data */
)
{
	DRESULT res = RES_ERROR;
	
    switch(cmd) {
    case CTRL_SYNC:
    	res = RES_OK;
    	break;
    case GET_SECTOR_SIZE:
		if (pdrv == SPI_FLASH_0) {
    		*(WORD*)buff = (WORD)w25q_spi_cs0->sectorSize; // in f_mkfs() [WORD ss] 
    		res = RES_OK;
		}
		if (pdrv == SPI_FLASH_1) {
    		*(WORD*)buff = (WORD)w25q_spi_cs1->sectorSize; // in f_mkfs() [WORD ss] 
    		res = RES_OK;
		}
    	break;
    case GET_BLOCK_SIZE:
		if (pdrv == SPI_FLASH_0) {
			*(DWORD*)buff = w25q_spi_cs0->blockSize;
			res = RES_OK;
		}
		if (pdrv == SPI_FLASH_1) {
			*(DWORD*)buff = w25q_spi_cs1->blockSize;
			res = RES_OK;
		}
    	break;
    case GET_SECTOR_COUNT:
		if (pdrv == SPI_FLASH_0) {
			*(DWORD*)buff = w25q_spi_cs0->sectorCount;
			res = RES_OK;
		}
		if (pdrv == SPI_FLASH_1) {
			*(DWORD*)buff = w25q_spi_cs1->sectorCount;
			res = RES_OK;
		}
    	break;
    default:
    	res = RES_PARERR;
    	break;
    }
    return res;
}

DWORD get_fattime(void) {
    datetime_t t = {0, 0, 0, 0, 0, 0, 0};
    bool rc = rtc_get_datetime(&t);
    if (!rc) return 0;

    DWORD fattime = 0;
    // bit31:25
    // Year origin from the 1980 (0..127, e.g. 37 for 2017)
    uint8_t yr = t.year - 1980;
    fattime |= (0b01111111 & yr) << 25;
    // bit24:21
    // Month (1..12)
    uint8_t mo = t.month;
    fattime |= (0b00001111 & mo) << 21;
    // bit20:16
    // Day of the month (1..31)
    uint8_t da = t.day;
    fattime |= (0b00011111 & da) << 16;
    // bit15:11
    // Hour (0..23)
    uint8_t hr = t.hour;
    fattime |= (0b00011111 & hr) << 11;
    // bit10:5
    // Minute (0..59)
    uint8_t mi = t.min;
    fattime |= (0b00111111 & mi) << 5;
    // bit4:0
    // Second / 2 (0..29, e.g. 25 for 50)
    uint8_t sd = t.sec / 2;
    fattime |= (0b00011111 & sd);
    return fattime;
}

  • spi_multi_flash_fatfs.c
#include <stdio.h>
#include "pico/stdlib.h"
#include "hardware/spi.h"
#include "W25Q.h"
#include "ff.h"
#include "diskio.h"
#include "hardware/flash.h"
#include "string.h"

#define FLASH_PATH_0 "0:"
#define FLASH_PATH_1 "1:"

FRESULT scan_files (
    char* path        /* Start node to be scanned (***also used as work area***) */
)
{
    FRESULT res;
    DIR dir;
    UINT i;
    static FILINFO fno;


    res = f_opendir(&dir, path);                       /* Open the directory */
    if (res == FR_OK) {
        for (;;) {
            res = f_readdir(&dir, &fno);                   /* Read a directory item */
            if (res != FR_OK || fno.fname[0] == 0) break;  /* Break on error or end of dir */
            if (fno.fattrib & AM_DIR) {                    /* It is a directory */
                i = strlen(path);
                sprintf(&path[i], "/%s", fno.fname);
                res = scan_files(path);                    /* Enter the directory */
                if (res != FR_OK) break;
                path[i] = 0;
            } else {                                       /* It is a file. */
                printf("%s/%s\n", path, fno.fname);
            }
        }
        f_closedir(&dir);
    }

    return res;
}

int main()
{
    stdio_init_all();

    FRESULT res;
    FATFS fs0, fs1;
    FIL fil0, fil1;
    UINT br;
    uint8_t work[4096*2];
    uint8_t readbuff[4096*2];
   
    res = f_mkfs(FLASH_PATH_0, 0, work, 4096);
    if(res != FR_OK) {
        printf("mkfs 0 error\n");
        return 1;
    }
    printf("\n\nmkfs 0 successfully(run only once): remove all data\n");

    res = f_mkfs(FLASH_PATH_1, 0, work, 4096);
    if(res != FR_OK) {
        printf("mkfs 1 error\n");
        return 1;
    }
    printf("mkfs 1 successfully(run only once): remove all data\n");

    // generator test data
    for (uint32_t i=0; i < 4096*2; i++) {
        uint8_t c = rand() % 127;
        if (c < 31) c+=31;
        work[i] = c;
    }

    printf("\nwrite buffer:200-300\n");
    for (uint32_t i = 200; i <= 300; i++) {
        printf("%c",work[i]);
    }
    printf("\n");

    //mount fs0
    res = f_mount(&fs0, FLASH_PATH_0, 1);
    if (res != FR_OK) {
        printf("mount 0 error\n");
        return 1;
    }

    // mount fs1
    res = f_mount(&fs1, FLASH_PATH_1, 1);
    if (res != FR_OK) {
        printf("mount drv 1 error\n");
        return 1;
    }

    res = f_open(&fil0, FLASH_PATH_0"/test_p01.txt", FA_CREATE_ALWAYS|FA_WRITE);
    f_write(&fil0, "01abc", 5, &br);
    f_close(&fil0);

    res = f_open(&fil0, FLASH_PATH_0"/test_p02.txt", FA_CREATE_ALWAYS|FA_WRITE);
    f_write(&fil0, "02abc", 5, &br);
    f_close(&fil0);

    res = f_open(&fil0, FLASH_PATH_0"/test.txt", FA_CREATE_ALWAYS|FA_WRITE);
    if (res != FR_OK) {
        printf("open error\n");
        return 1;
    }
    res = f_write(&fil0, work, 4096*2, &br);
    f_close(&fil0);

    res = f_open(&fil1, FLASH_PATH_1"/pat1_p11.txt", FA_CREATE_ALWAYS|FA_WRITE);
    f_close(&fil1);
    res = f_open(&fil1, FLASH_PATH_1"/pat1_p12.txt", FA_CREATE_ALWAYS|FA_WRITE);
    f_close(&fil1);

    res = f_open(&fil1, FLASH_PATH_1"/test.txt", FA_CREATE_ALWAYS|FA_WRITE);
    if (res != FR_OK) {
        printf("open 1 error\n");
        return 1;
    }

    // change some data and write into FLASH_PATH_1
    memcpy(work+200, "FLASH_1", 7);
    f_write(&fil1, work, 4096*2, &br);
    f_close(&fil1);
    
    res = f_open(&fil0, FLASH_PATH_0"/test.txt", FA_READ);
    if (res != FR_OK) {
        printf("read open error\n");
        return 1;
    }
    f_read(&fil0, readbuff, 4096*2, &br);
    printf("\nread FLASH_PATH_0/test.txt buff:200-300\n");
    for (uint32_t i = 200; i <= 300; i++) {
        printf("%c",readbuff[i]);
    }
    printf("\n");
    
    res = f_open(&fil1, FLASH_PATH_1"/test.txt", FA_READ);
    if (res != FR_OK) {
        printf("read open 1 error\n");
        return 1;
    }
    
    f_read(&fil1, readbuff, 4096*2, &br);
    printf("\nread FLASH_PATH_1/test.txt buff:200-300\n");
    for (uint32_t i = 200; i <= 300; i++) {
        printf("%c",readbuff[i]);
    }
    printf("\n");
    f_close(&fil0);
    f_close(&fil1);

    printf("\nlist all files in  FLASH_PATH_0\n");
    scan_files(FLASH_PATH_0);

    printf("\nlist all files in  FLASH_PATH_1\n");
    scan_files(FLASH_PATH_1);

    f_unmount(FLASH_PATH_0);
    f_unmount(FLASH_PATH_1);

    
    return 0;
}